论文
2026
 工业检测Physically inspired geometry-to-photometry rendering and lightweight convolutional neural network for real-time weld defect detection.Engineering Applications of Artificial Intelligence, 185:116464.
 6D位姿与机器人 ActuatorsFusing Phase Map Servoing and MPC for High-Precision Robotic Tracking of Dynamic Objects.Actuators, 15(2):77.
 几何处理3D Surface Matching Based on Adaptive Threshold and Curvature Map.2026 9th International Conference on Image and Graphics Processing (ICIGP), 419-424.
 光学与图像处理A Grayscale-Compatible Color Encoding via 8-bit HSV Bit-Packing and Lightweight Refinement.Available at SSRN 7273824.[Bib]
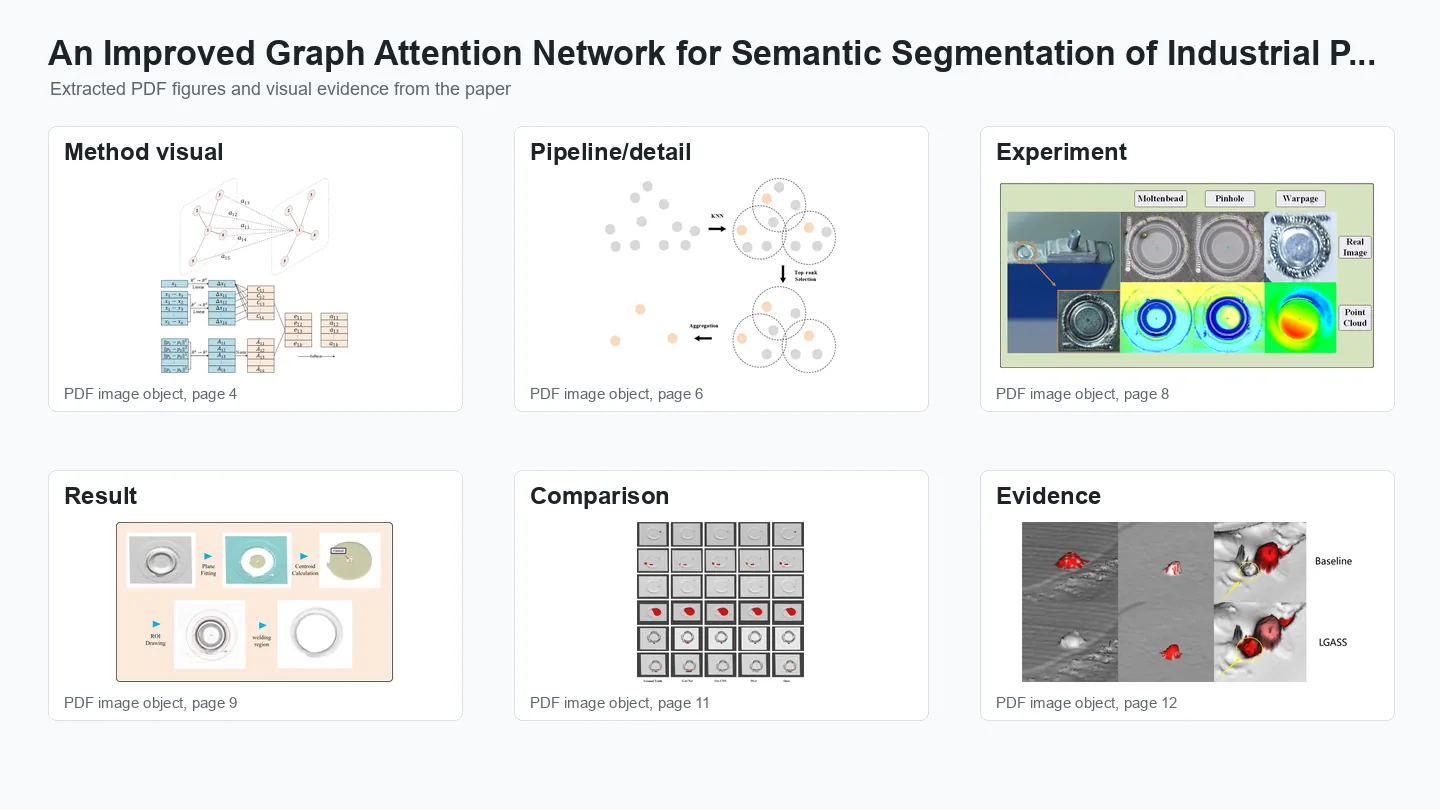 工业检测An Improved Graph Attention Network for Semantic Segmentation of Industrial Point Clouds in Automotive Battery Sealing Nail Defect Detection.Engineering Applications of Artificial Intelligence, 163(1):112793.
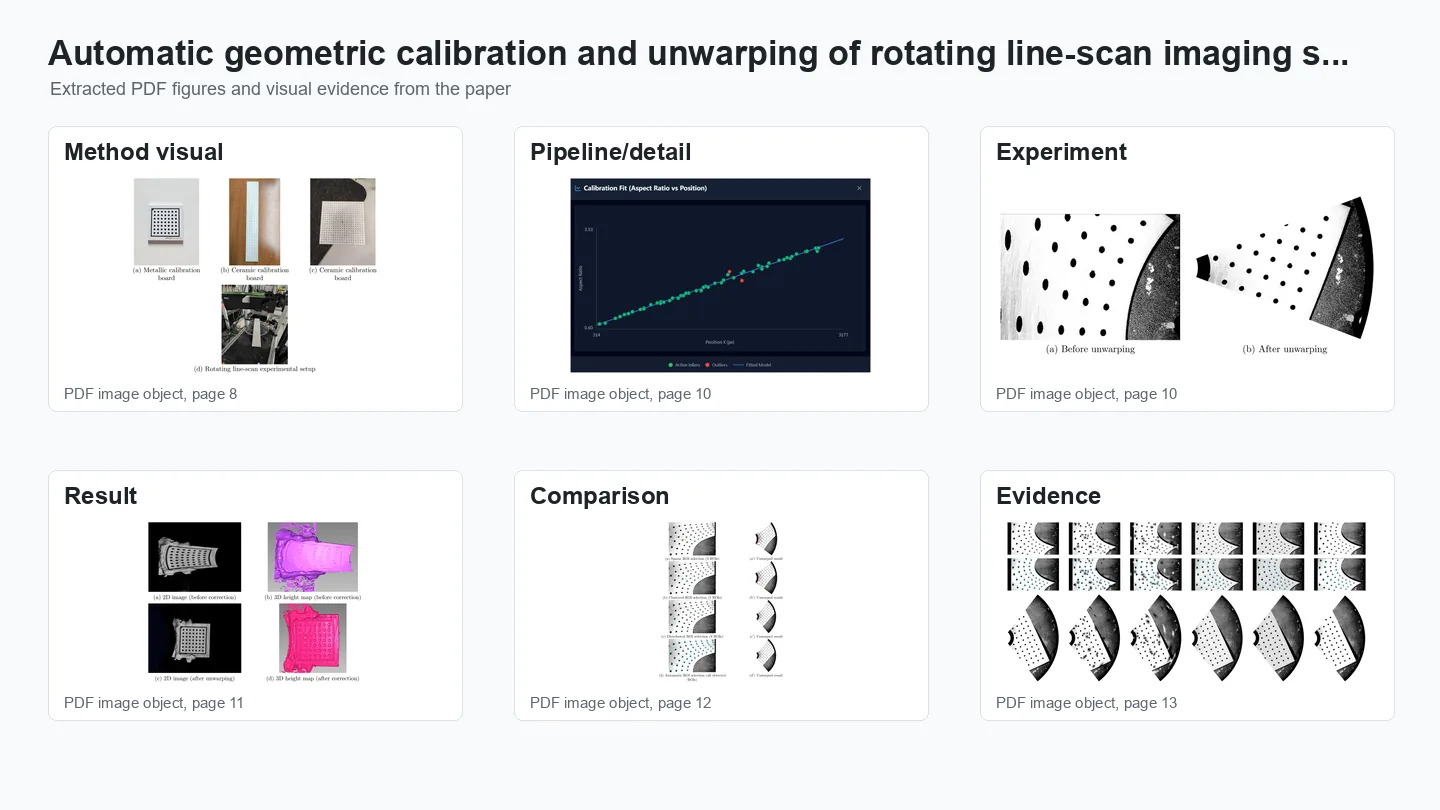 工业检测Automatic geometric calibration and unwarping of rotating line-scan imaging systems using elliptical distortion of circular patterns.Optics and Lasers in Engineering, 203:109793.
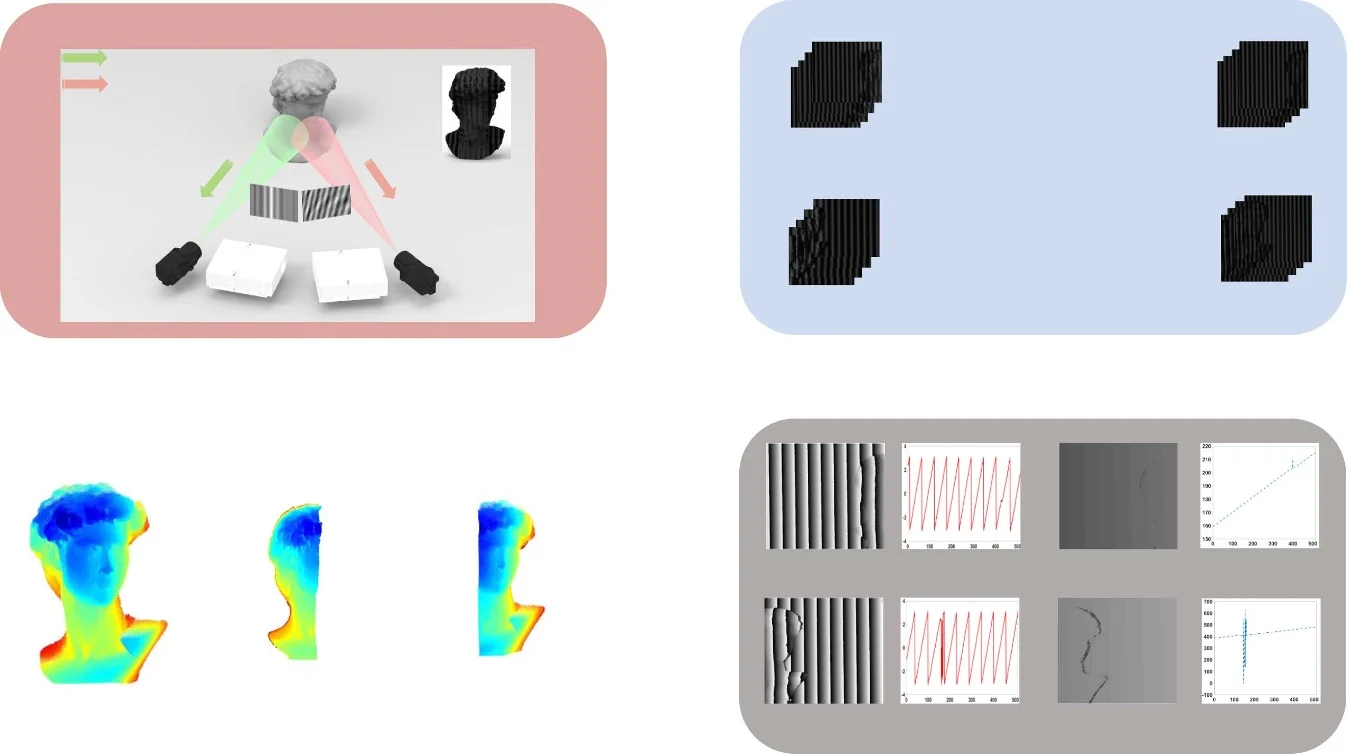 结构光与三维成像 Measurement Science and TechnologyDeep diffusion model-based dual structured light for large-format complex surface imaging.Measurement Science and Technology, 37(6):065009.
 工业检测Depth-adaptive calibration of line-laser 3D measurement systems using rational polynomial mapping and depth-independent misalignment compensation.Optics & Laser Technology, 204:116090.
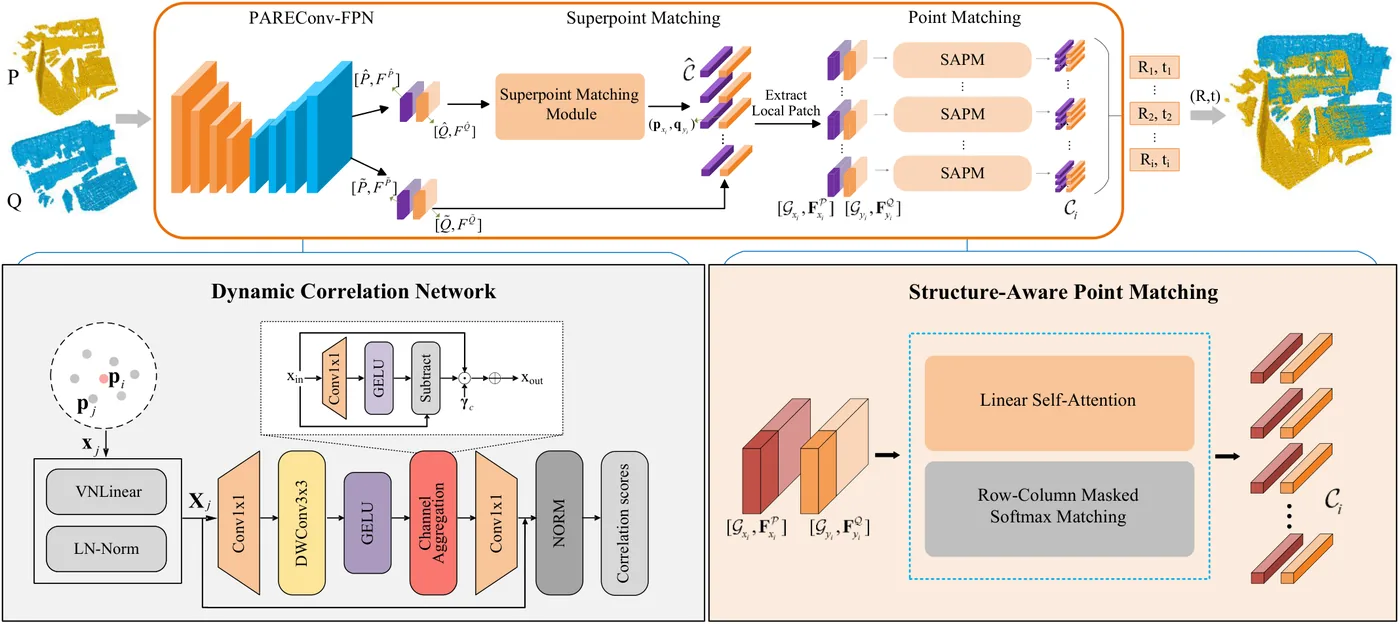 点云配准Dynamic correlation network and structure-aware matching for robust point cloud registration.Computers & Graphics, 104672.
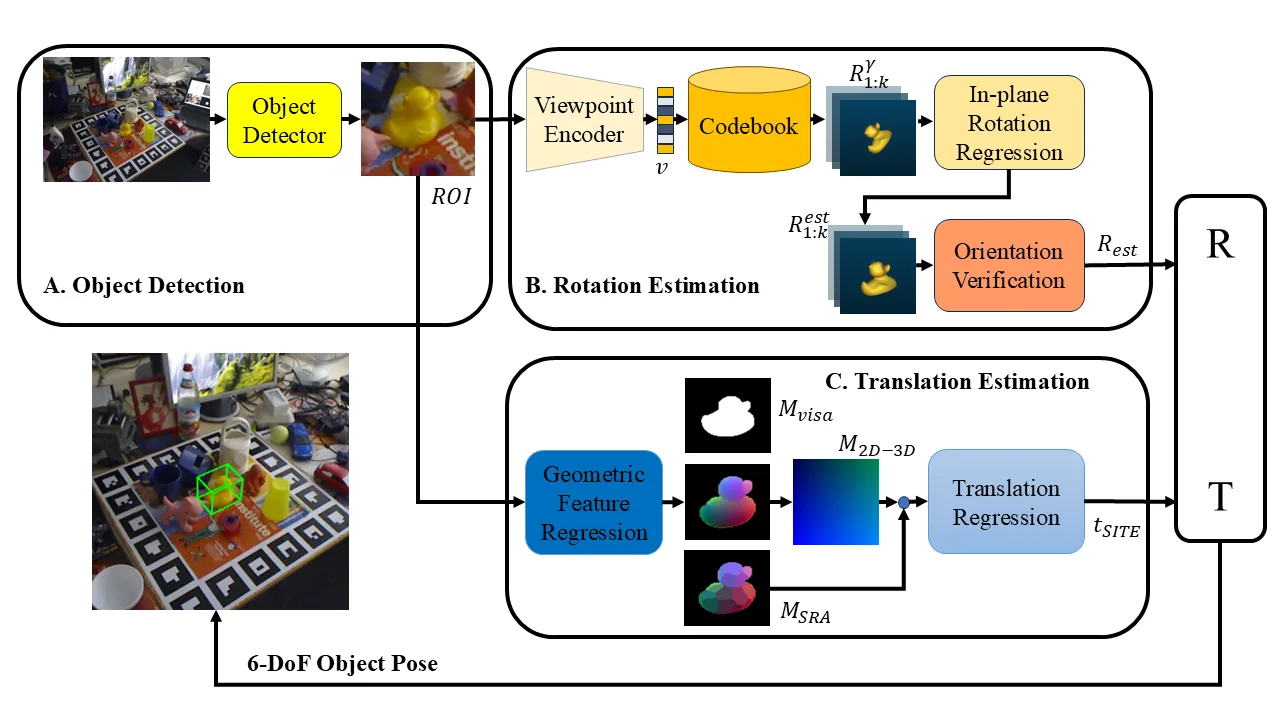 6D位姿与机器人Few-Shot 6D Object Pose Estimation via Decoupled Rotation and Translation with Viewpoint Encoding.Electronics, 15(3):561.
- LBROM结构光与三维成像Learning-based reconstruction of moving transparent objects.International Conference on Optoelectronic Science and Intelligent Sensing (SPIE), 1417511.
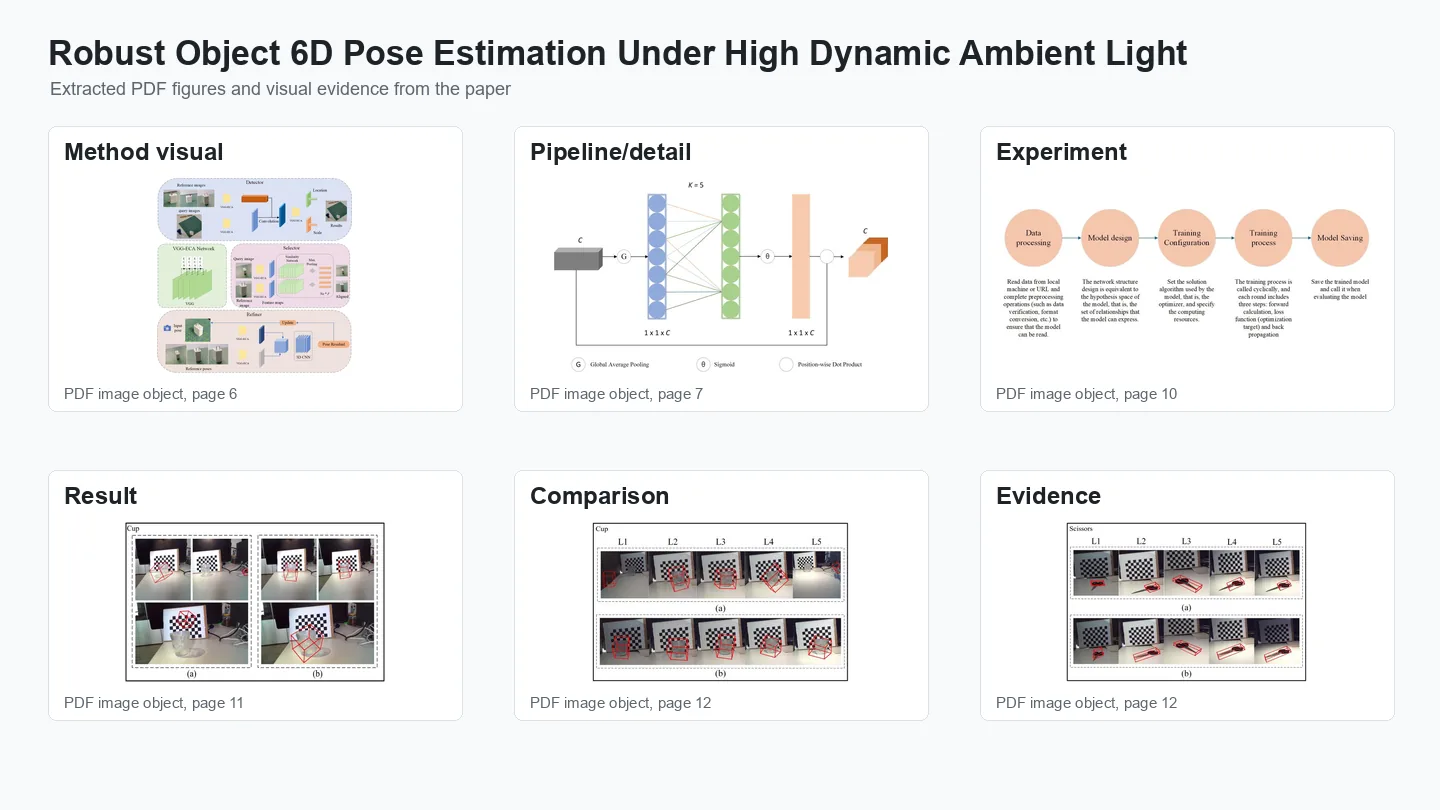 6D位姿与机器人Robust Object 6D Pose Estimation Under High Dynamic Ambient Light.Computer-Aided Design and Applications, 23(4):411-427.
- SCSLT结构光与三维成像Self-calibrating structured light three-dimensional imaging method with fringe projection.International Conference on Optical Communication, Signal Processing, and Optical Engineering (SPIE), 1418516.
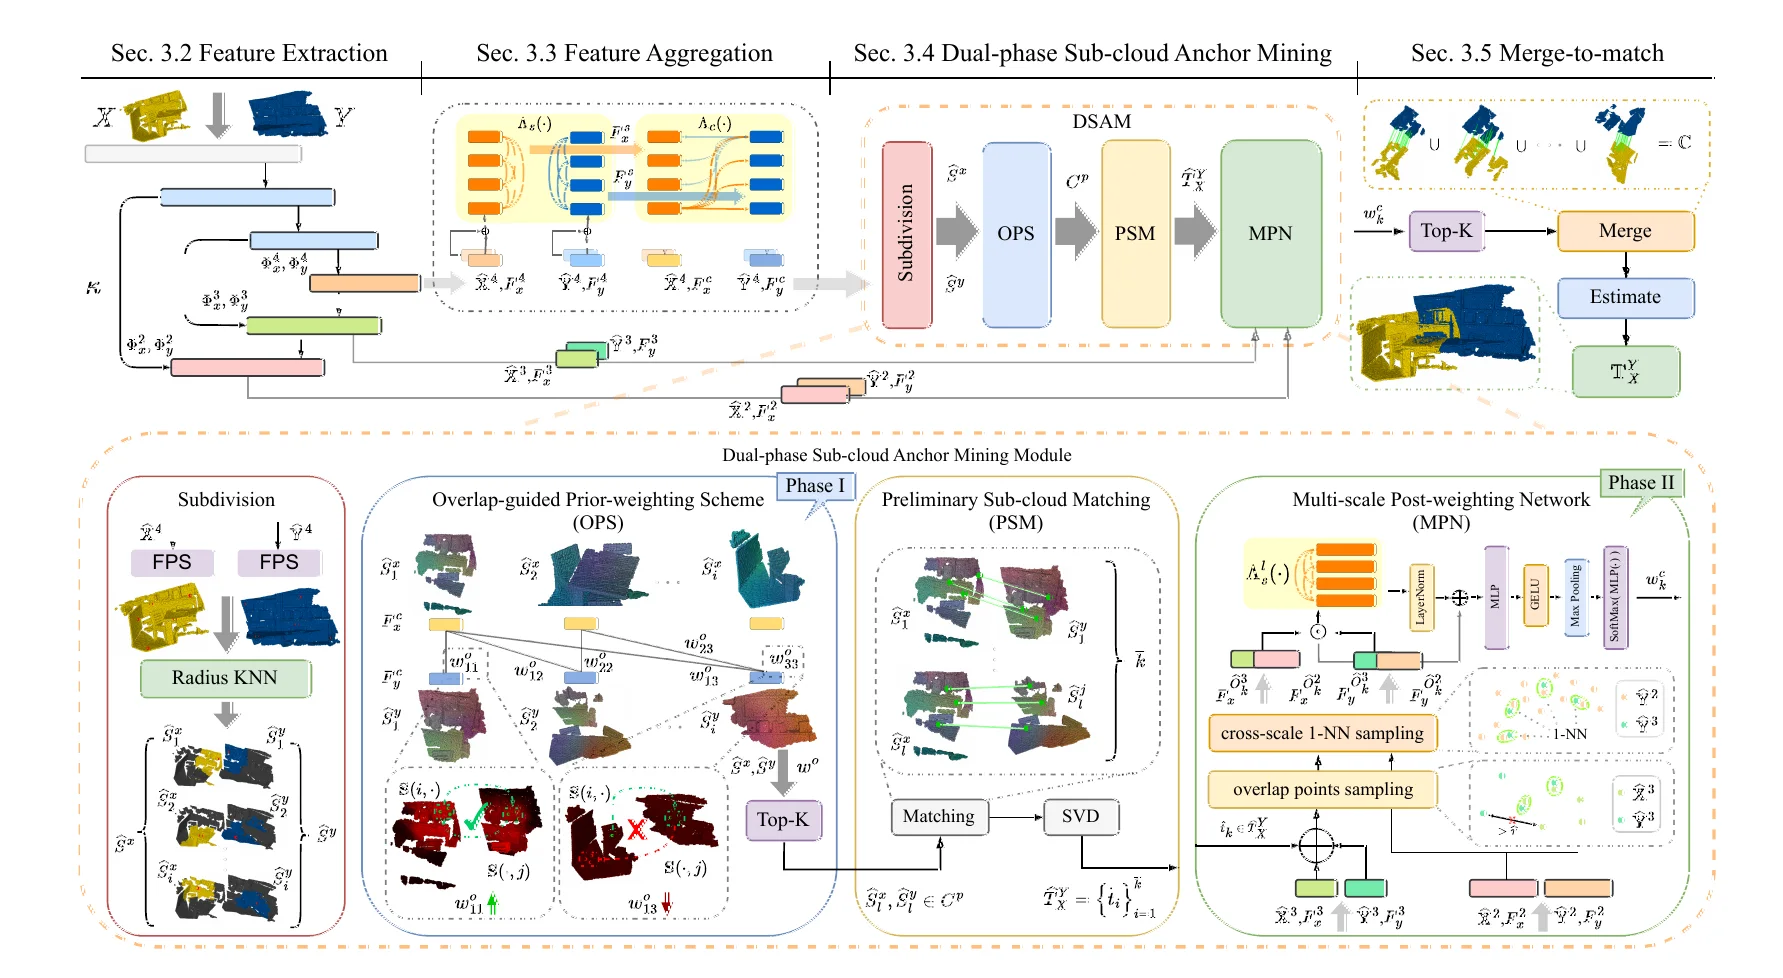 点云配准 ★ CVPR 2026 HighlightSuP: Sub-cloud Driven Point Cloud Registration.IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 24185-24194 - Highlight.
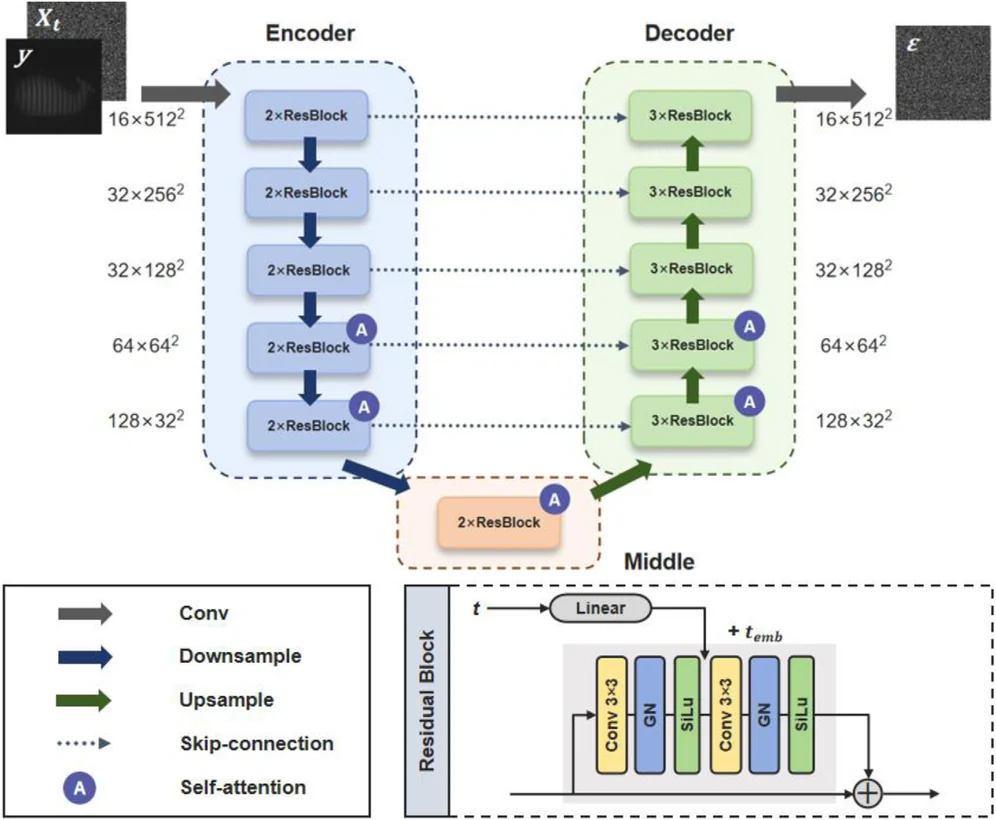 结构光与三维成像 Applied OpticsUnderwater structured-light 3D imaging method based on FP-DiffNet.Applied Optics, 65(10):3138-3148.
2025
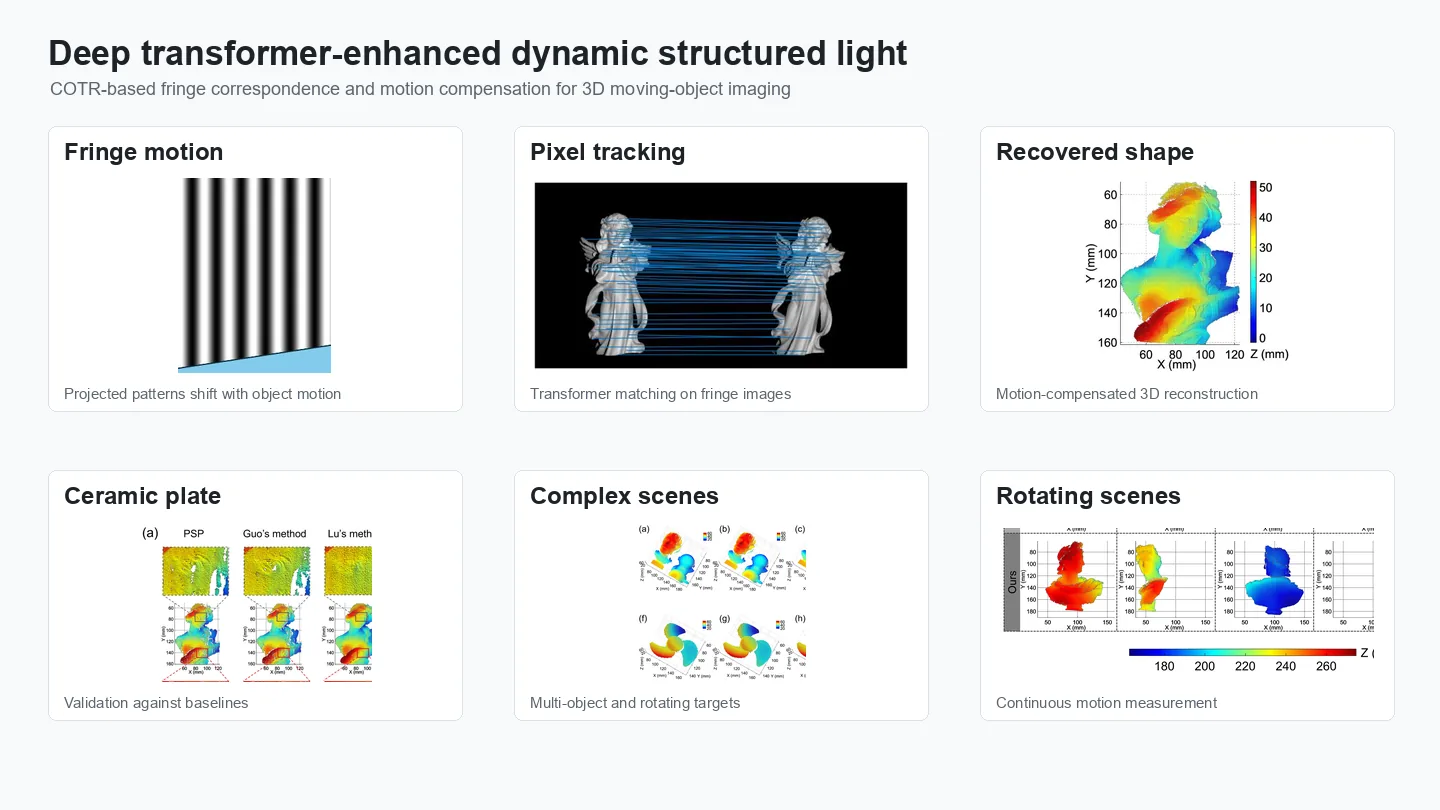 结构光与三维成像 Optics ExpressDeep transformer-enhanced dynamic structured light for three-dimensional moving object imaging.Optics Express, 33(25):52084-52104.
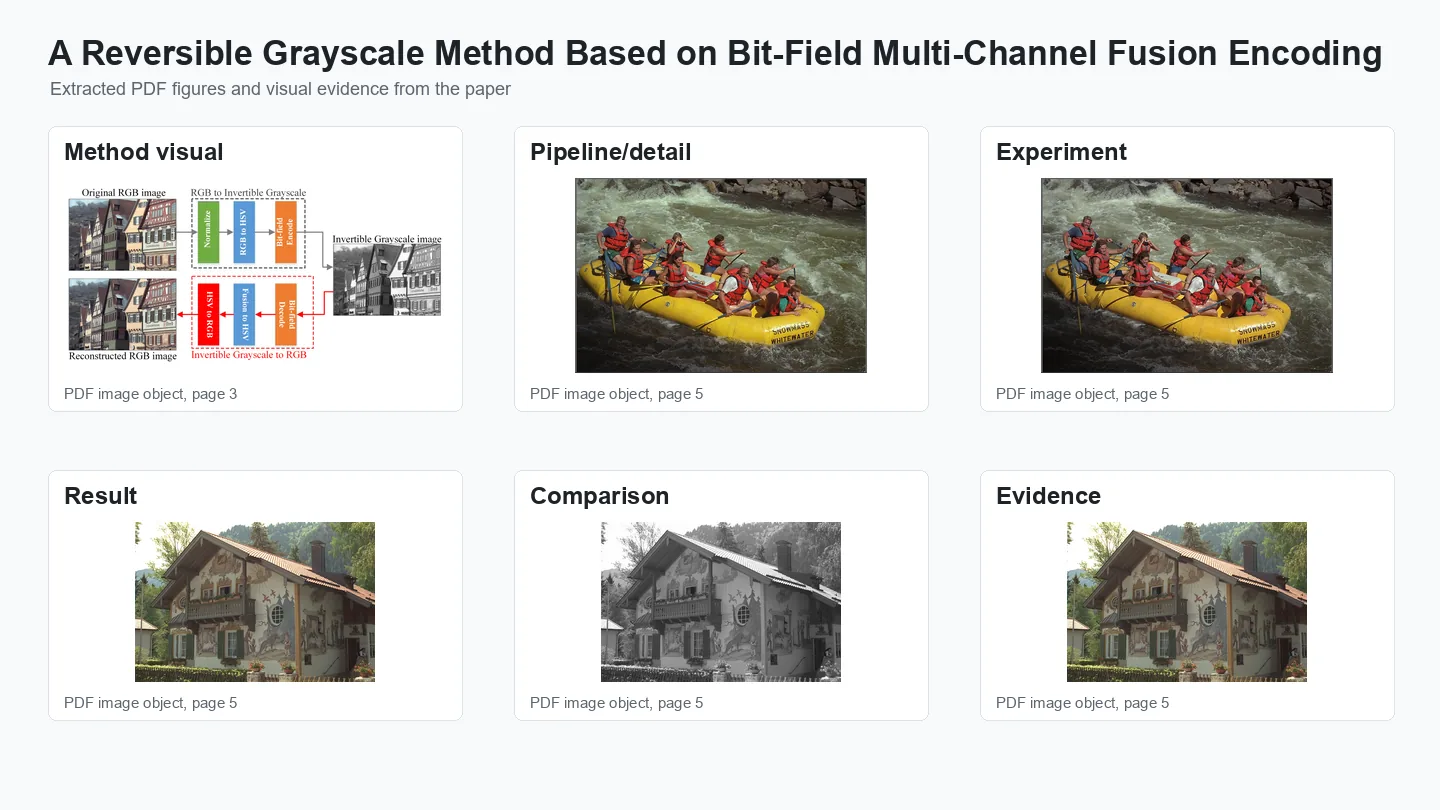 光学与图像处理A Reversible Grayscale Method Based on Bit-Field Multi-Channel Fusion Encoding.2025 10th International Conference on Image, Vision and Computing (ICIVC), 555-560.
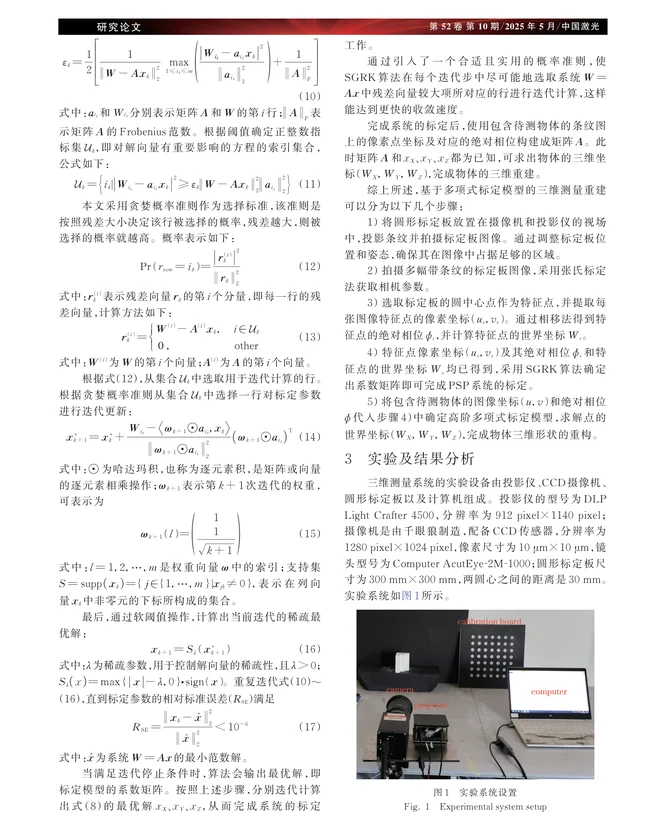 光学与图像处理Calibration Method of Fringe Projection Based on High-Order Polynomial.Chinese Journal of Lasers, 52(10):1004002-1004002.
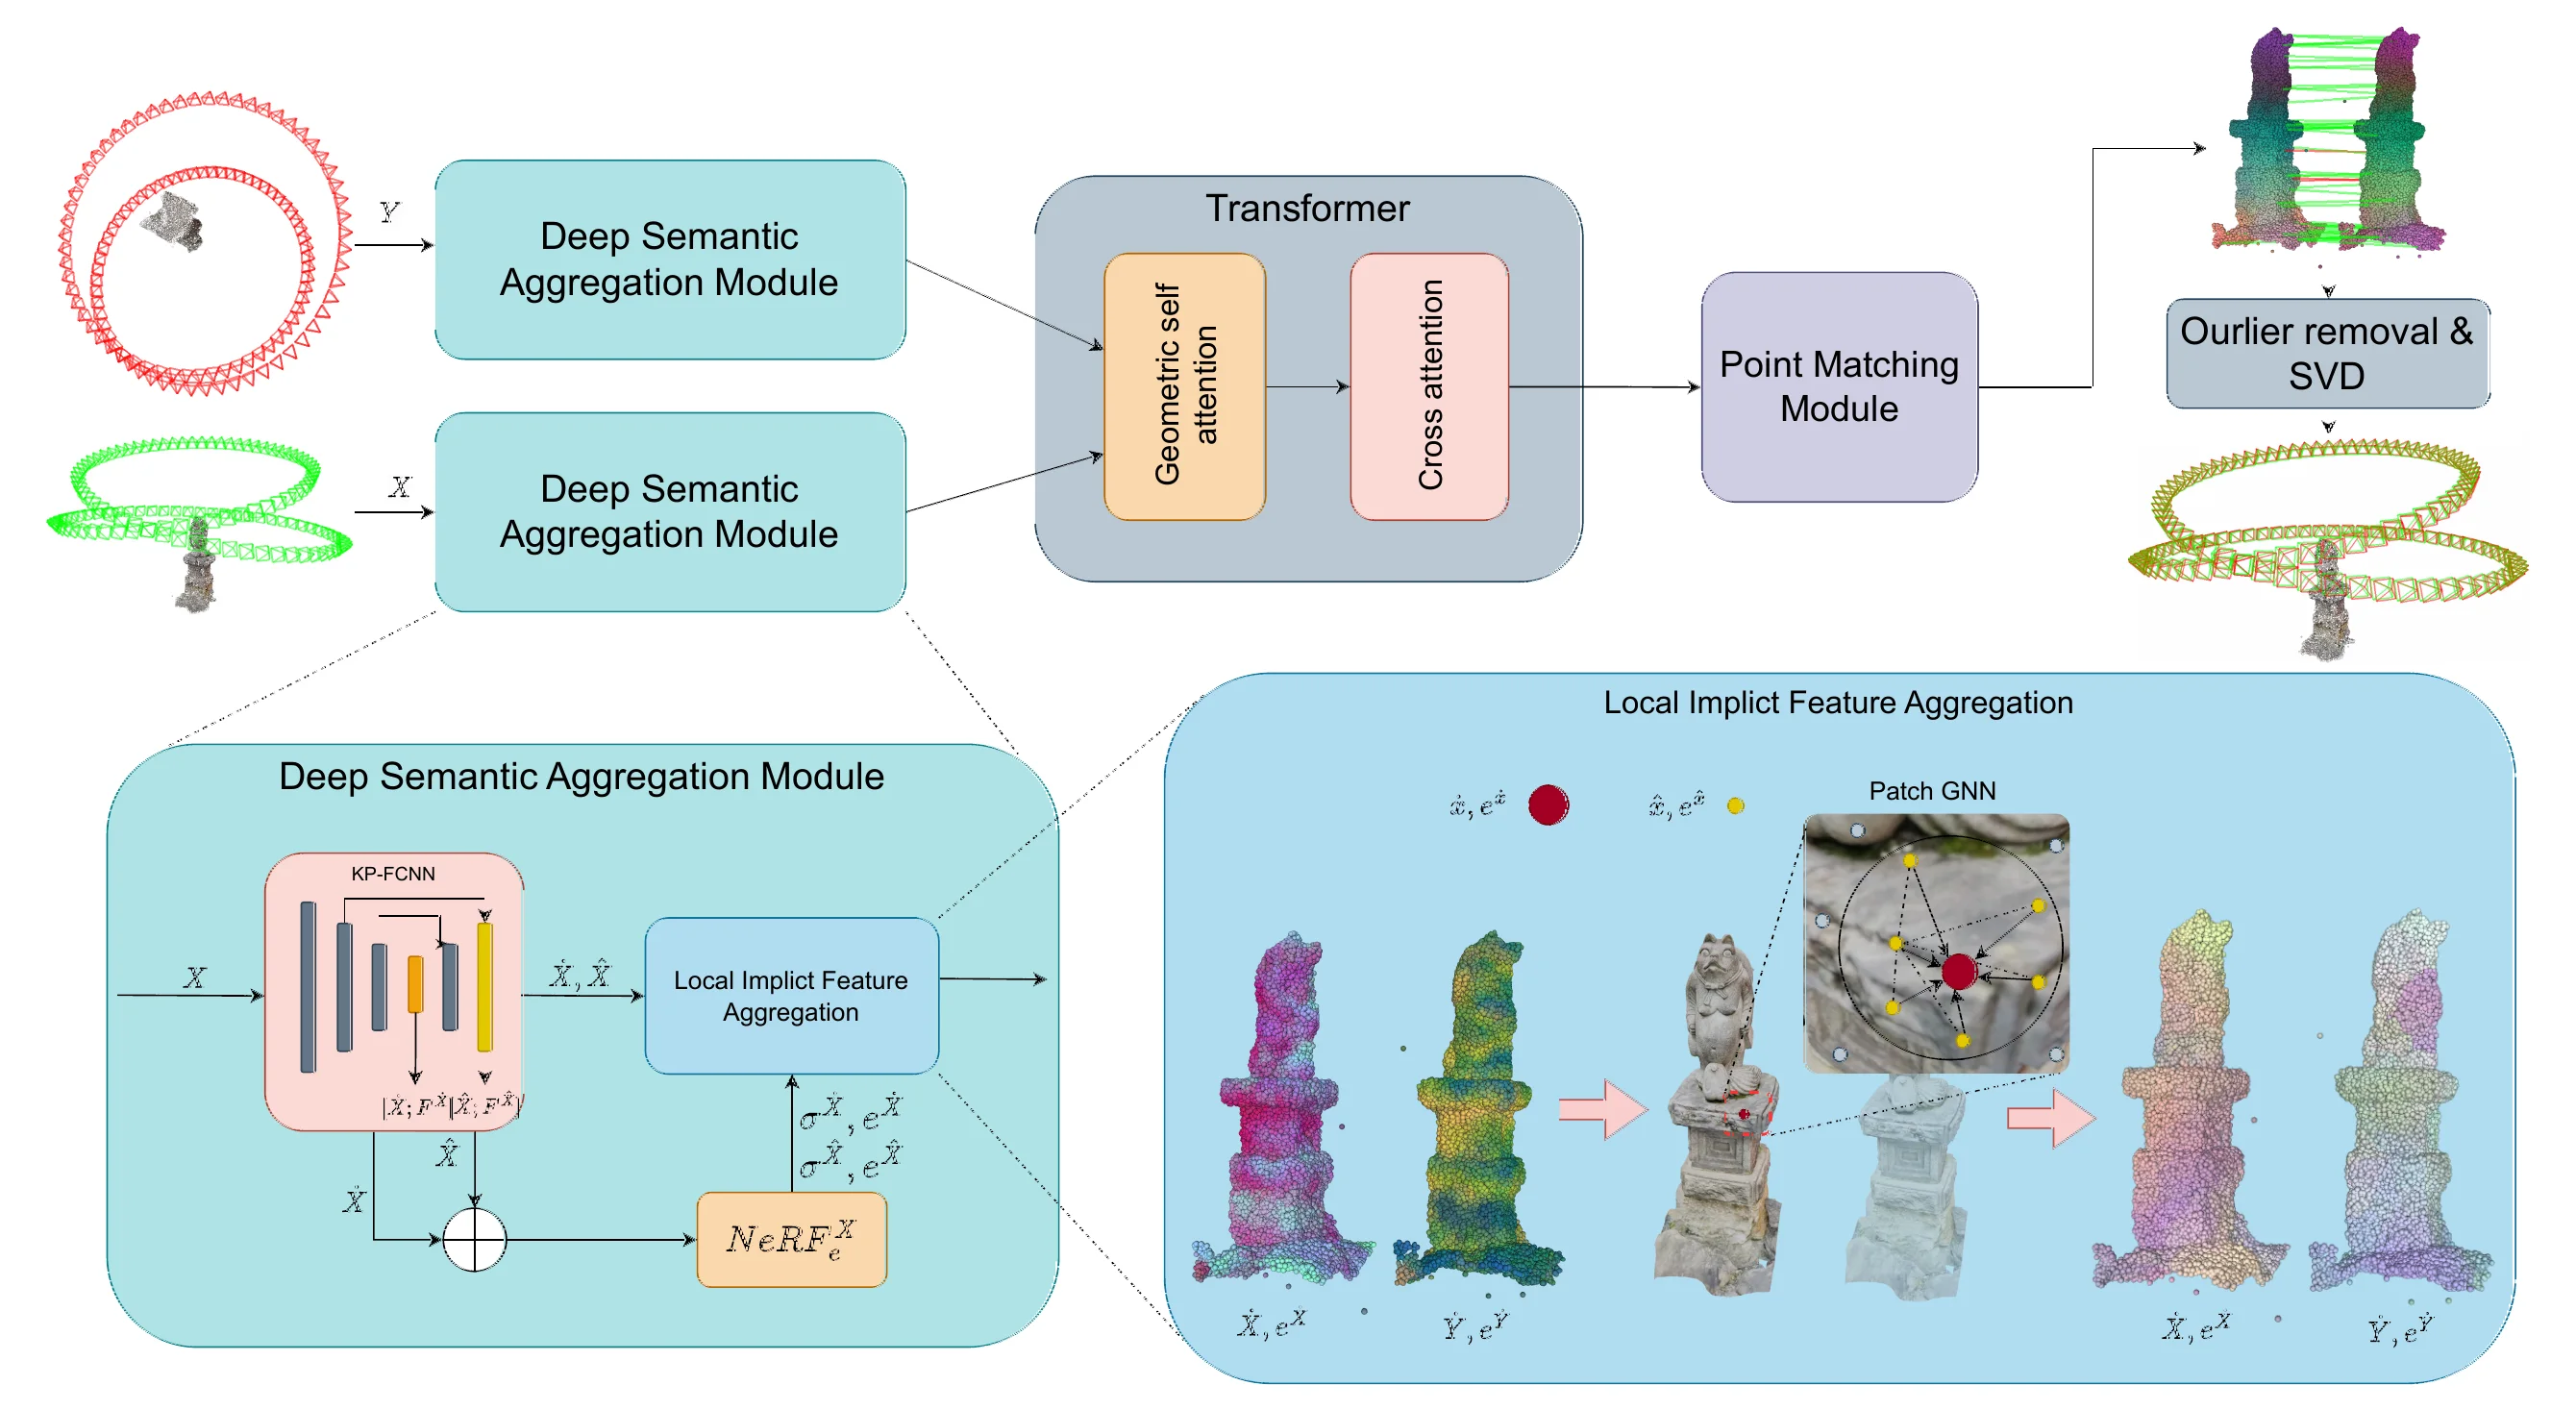 点云配准 IEEE TVCGDeSC: Learning Deep Semantic Descriptor for NeRF Registration.IEEE Transactions on Visualization and Computer Graphics.
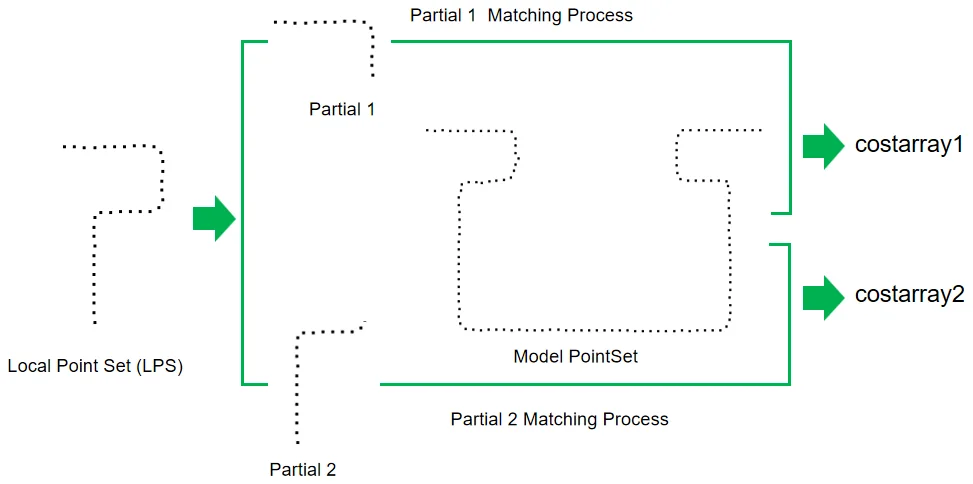 计算设计 CAD&AFast Shape Retrieval Based on Differential Chain Code Descriptor and Fuzzy Contour Matching.Computer-Aided Design and Applications, 23(2):222-233.
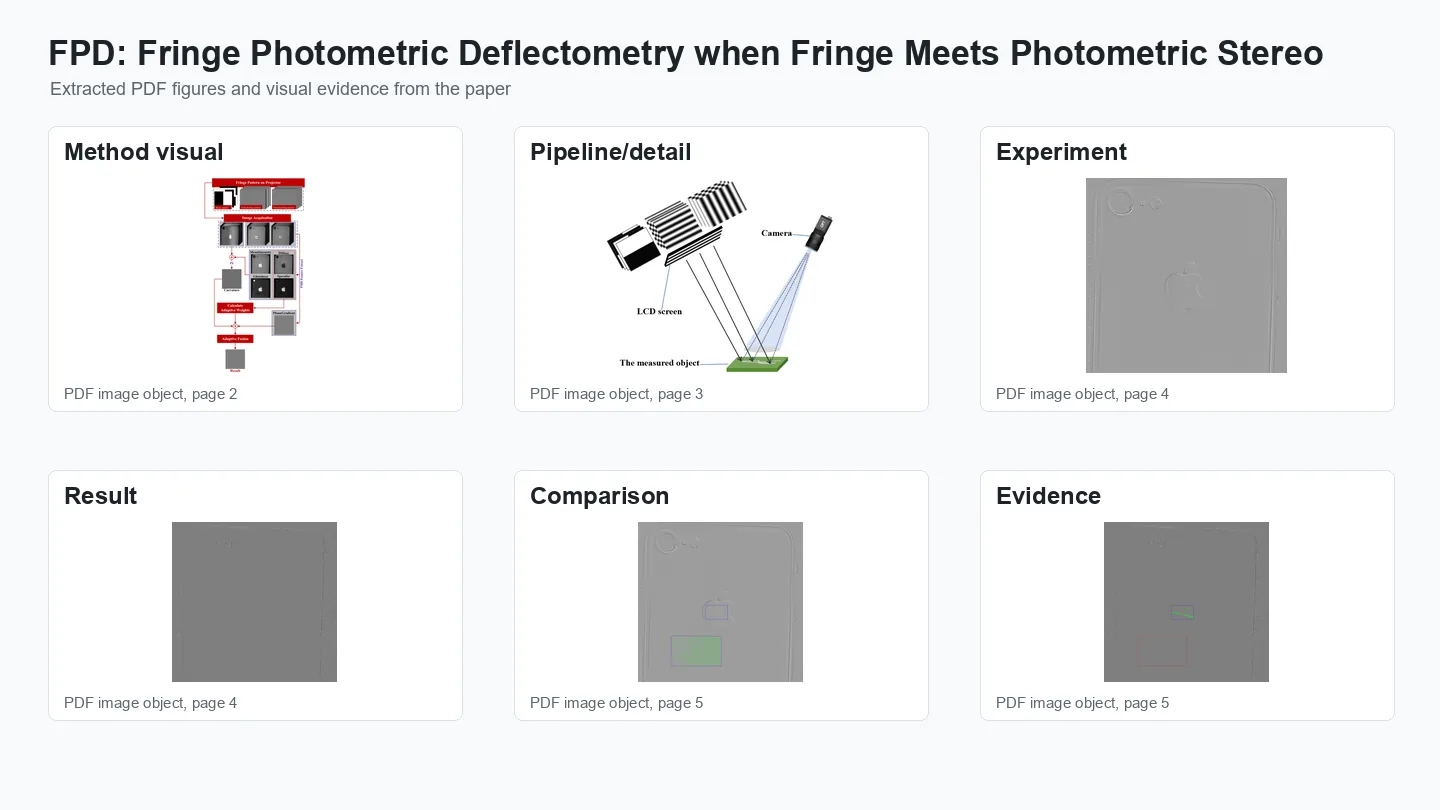 工业检测FPD: Fringe Photometric Deflectometry when Fringe Meets Photometric Stereo.2025 10th International Conference on Image, Vision and Computing (ICIVC), 408-413.
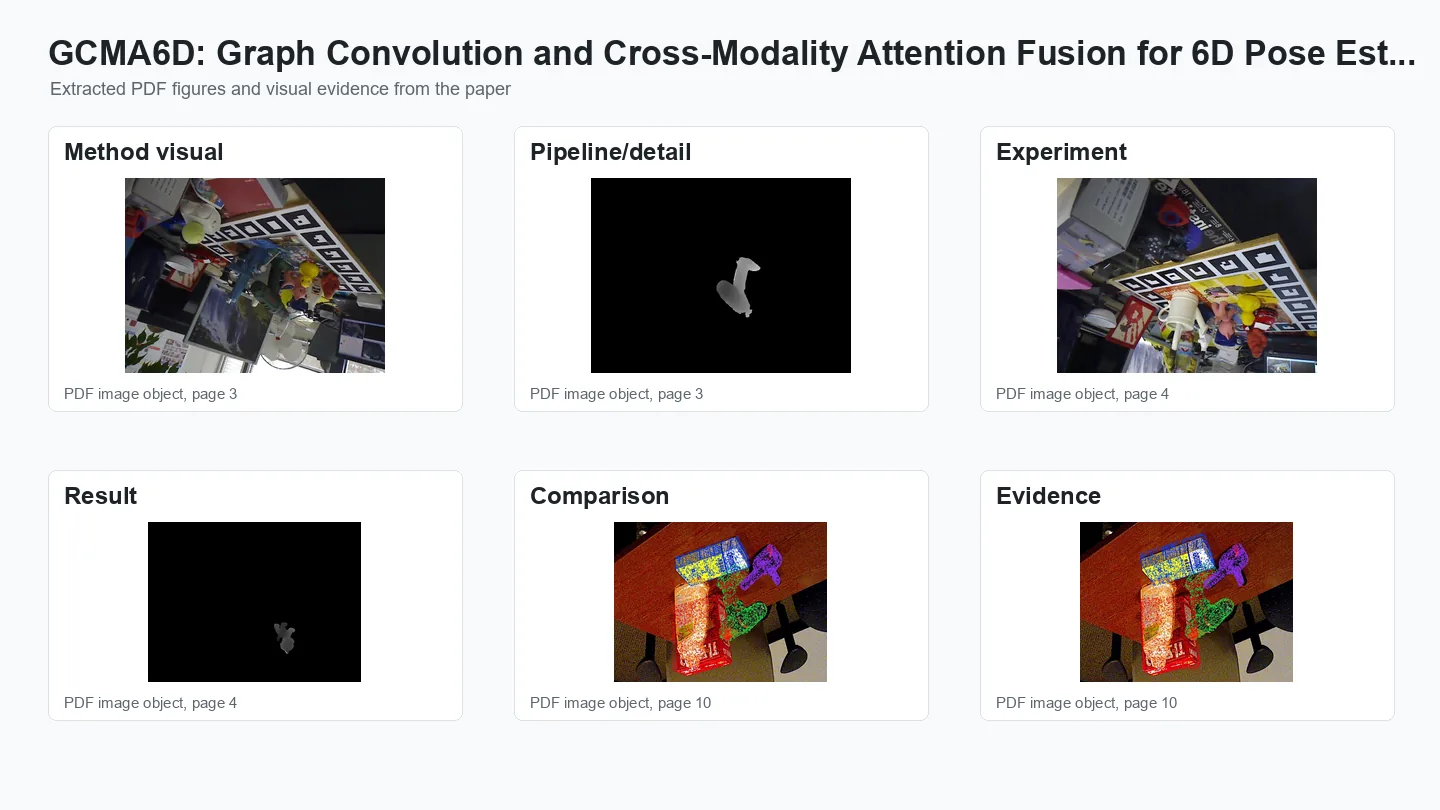 6D位姿与机器人GCMA6D: Graph Convolution and Cross-Modality Attention Fusion for 6D Pose Estimation.Proceedings of the Australasian Conference on Robotics and Automation (ACRA 2025).
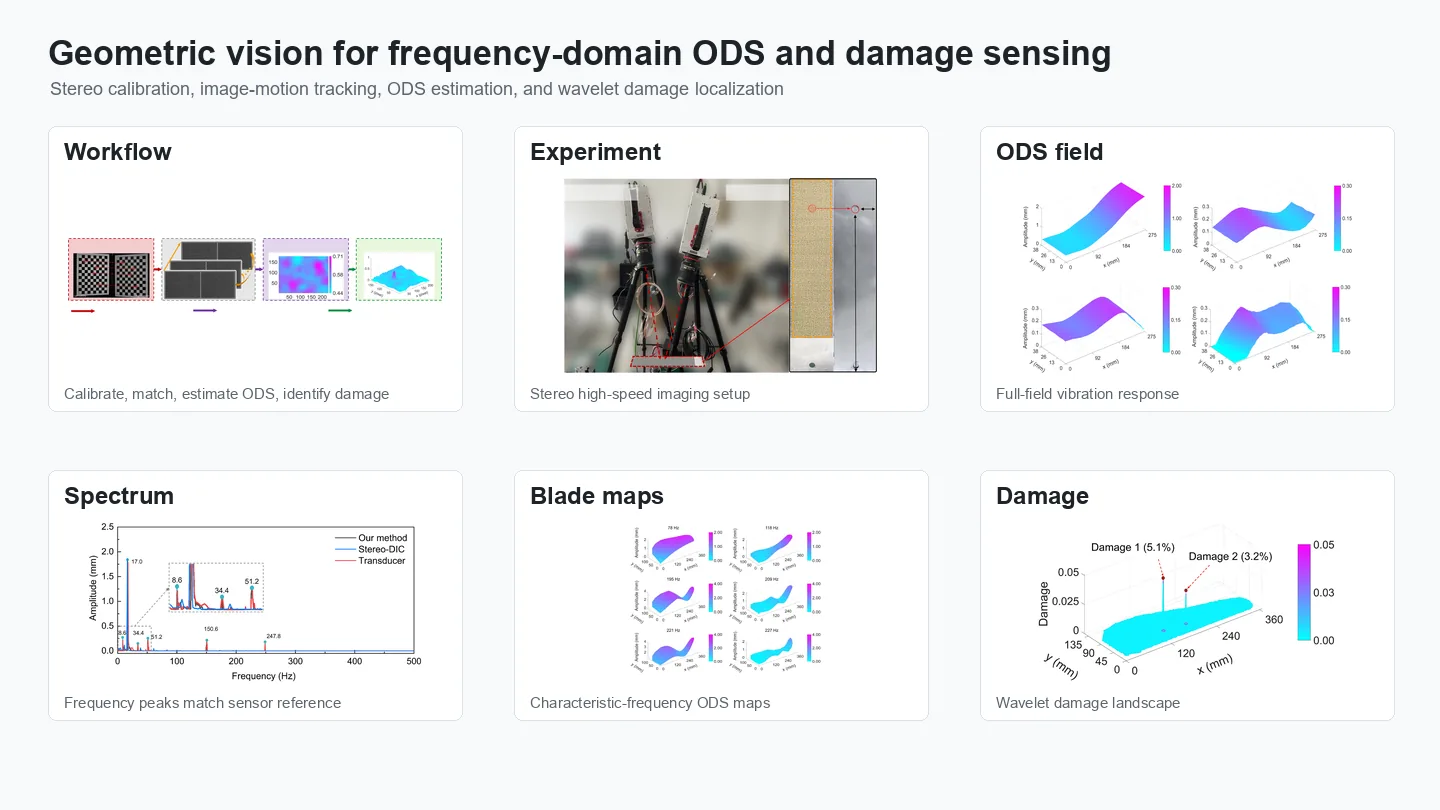 光学与图像处理 Results in EngineeringIdentifying frequency-domain operating deflection shapes and internal damage in structures using geometric vision method.Results in Engineering, 29:108474.
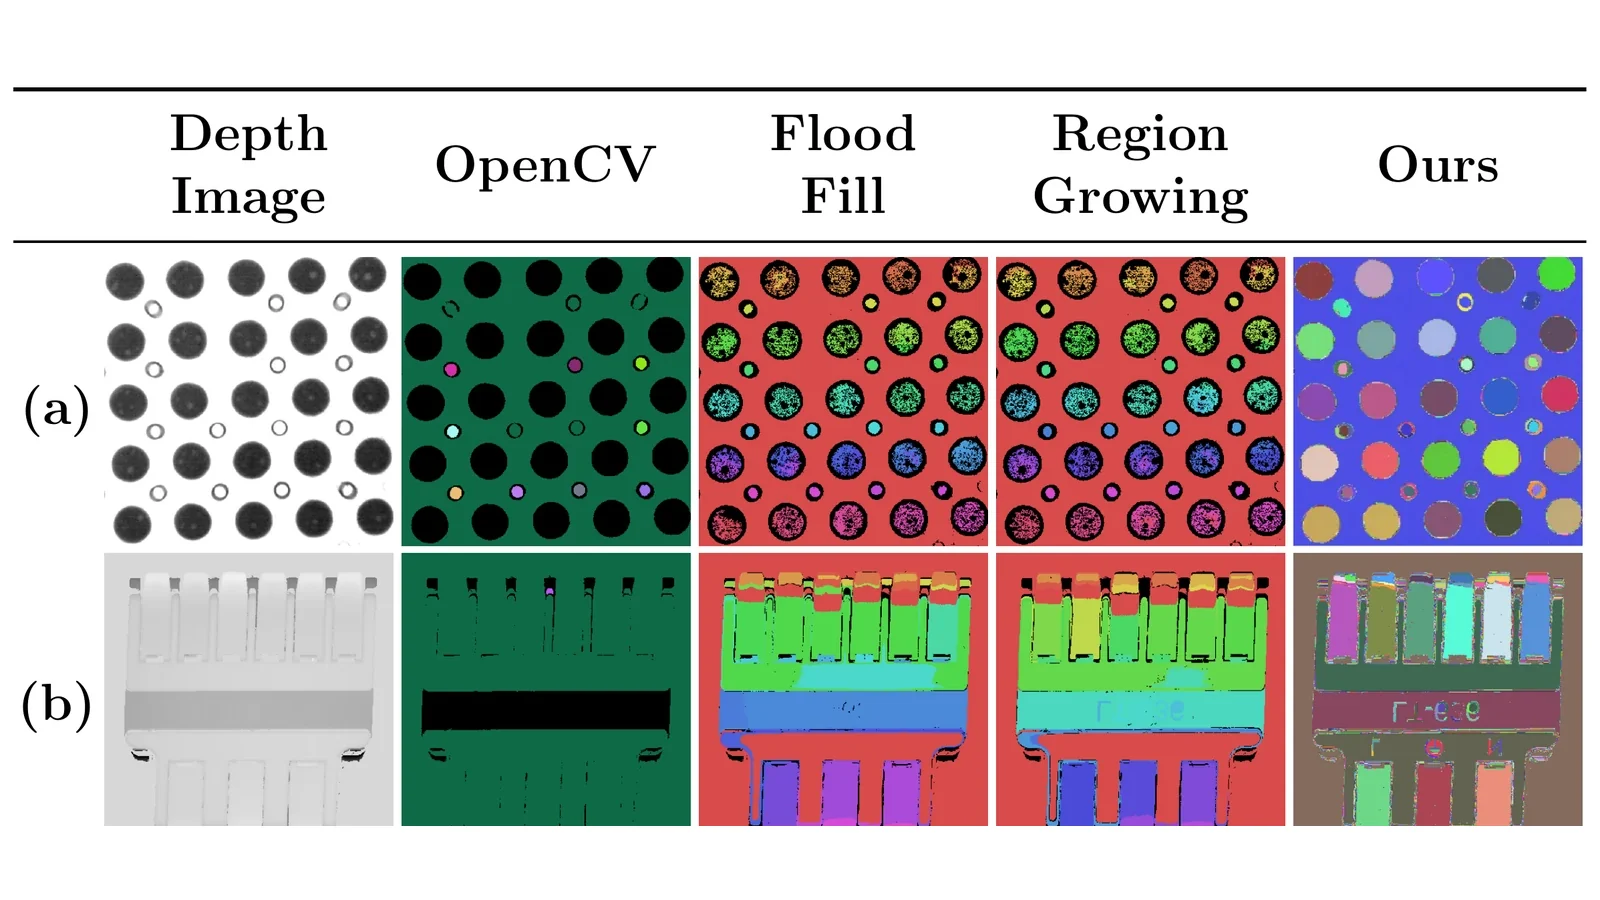 光学与图像处理Parallel Grayscale Connected Component Analysis via Neighborhood Labeling and Global Region Mapping.SSRN preprint 5854925.
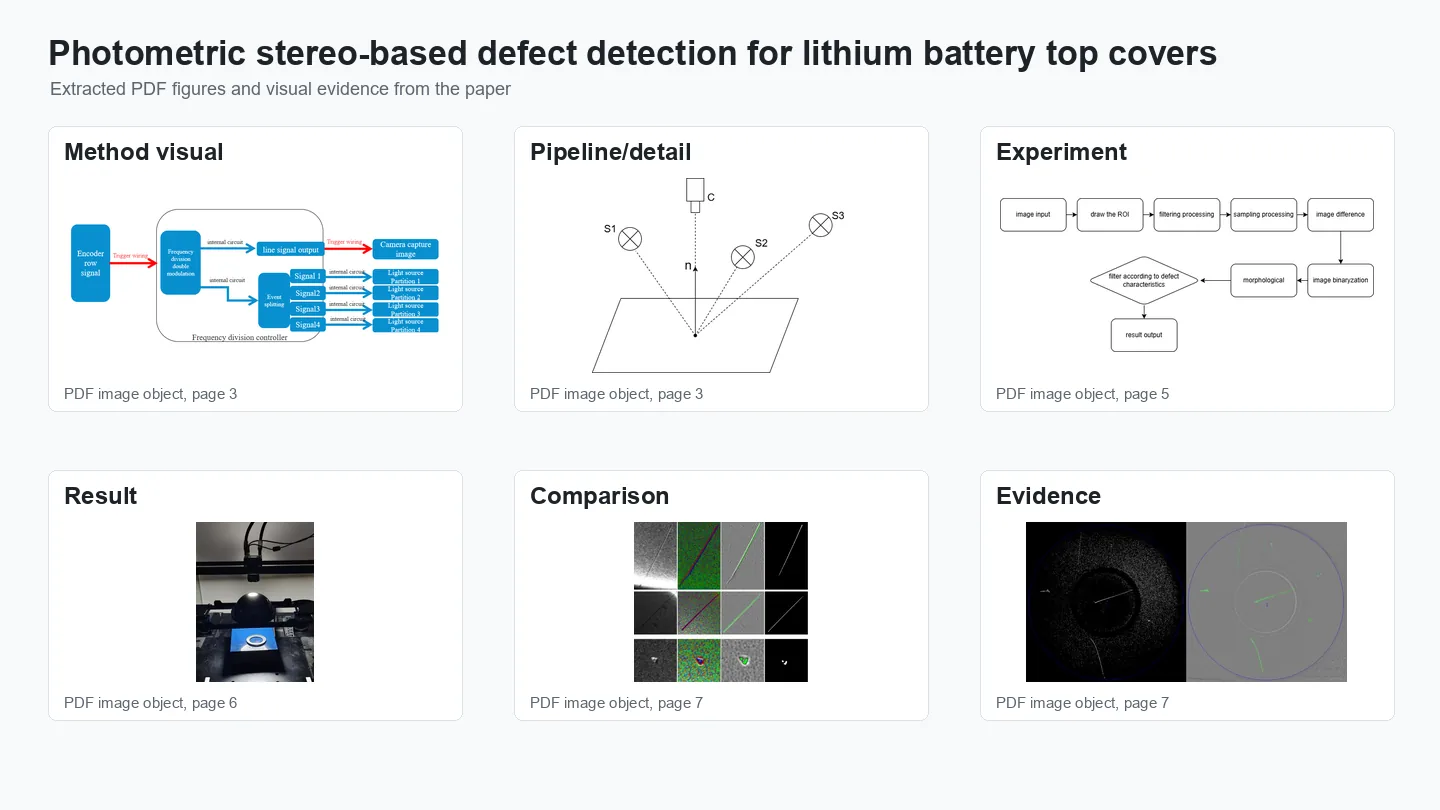 工业检测Photometric stereo-based defect detection for lithium battery top covers.Seventh International Conference on Image Processing and Machine Vision (IPMV 2025), vol. 13636, 100-107.
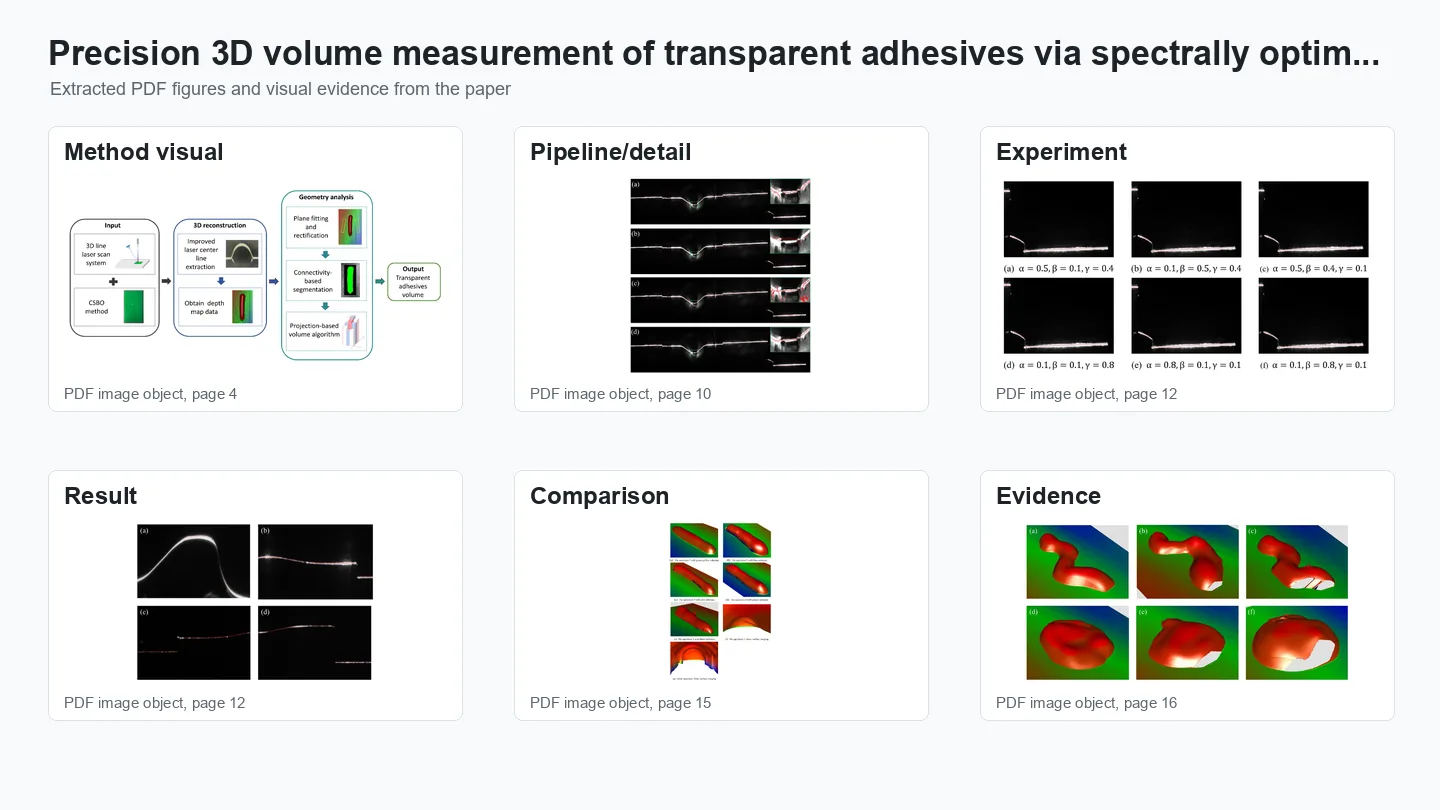 工业检测Precision 3D volume measurement of transparent adhesives via spectrally optimized line laser scanning and enhanced centroid extraction.Measurement Science and Technology, 36(11):115206.
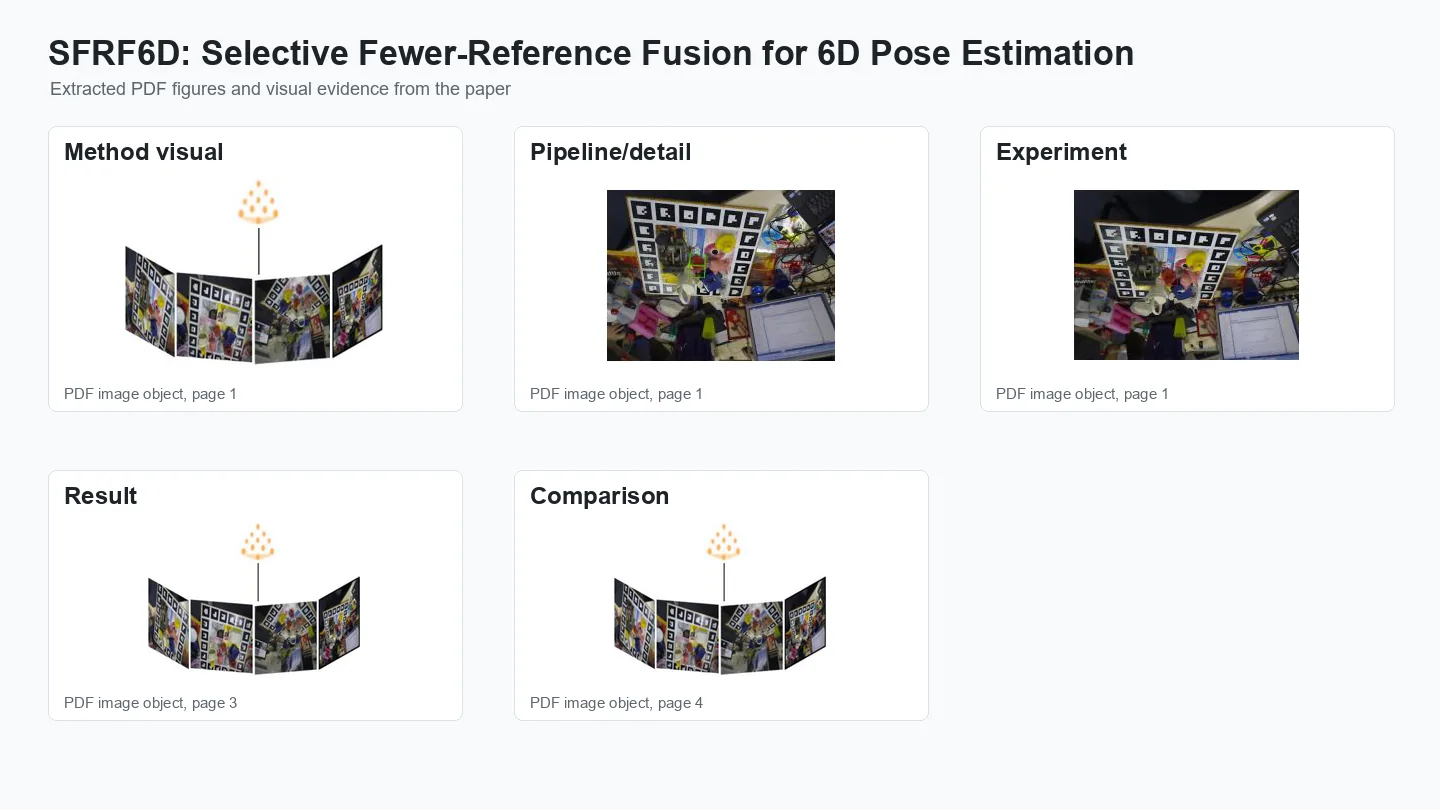 6D位姿与机器人SFRF6D: Selective Fewer-Reference Fusion for 6D Pose Estimation.Proceedings of the Australasian Conference on Robotics and Automation (ACRA 2025).
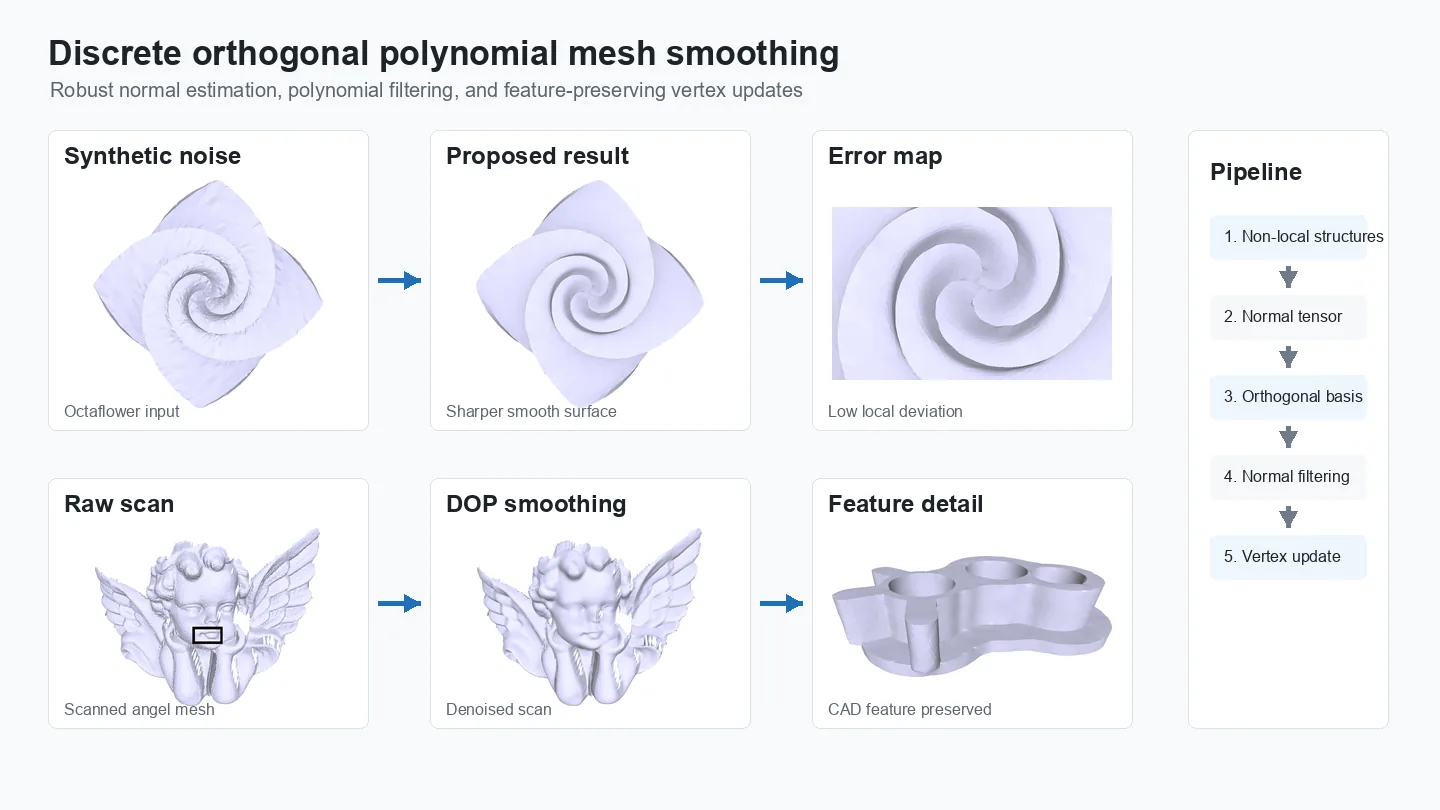 几何处理 CAD&ASurface Smoothing based on Discrete Orthogonal Polynomial.Computer-Aided Design and Applications, 22(6):1027-1039.
2024
 生物医学与生物识别VeinTr: Robust end-to-end full-hand vein identification with transformer.The Visual Computer, 40(10):7015–7023.
 几何处理 The Visual ComputerSegmentation-Driven Feature-Preserving Mesh Denoising.The Visual Computer, 40(9):6201-6217.
 点云配准 ECCV 2024SemReg: Semantics-Constrained Point Cloud Registration.European Conference on Computer Vision (ECCV) 2024.
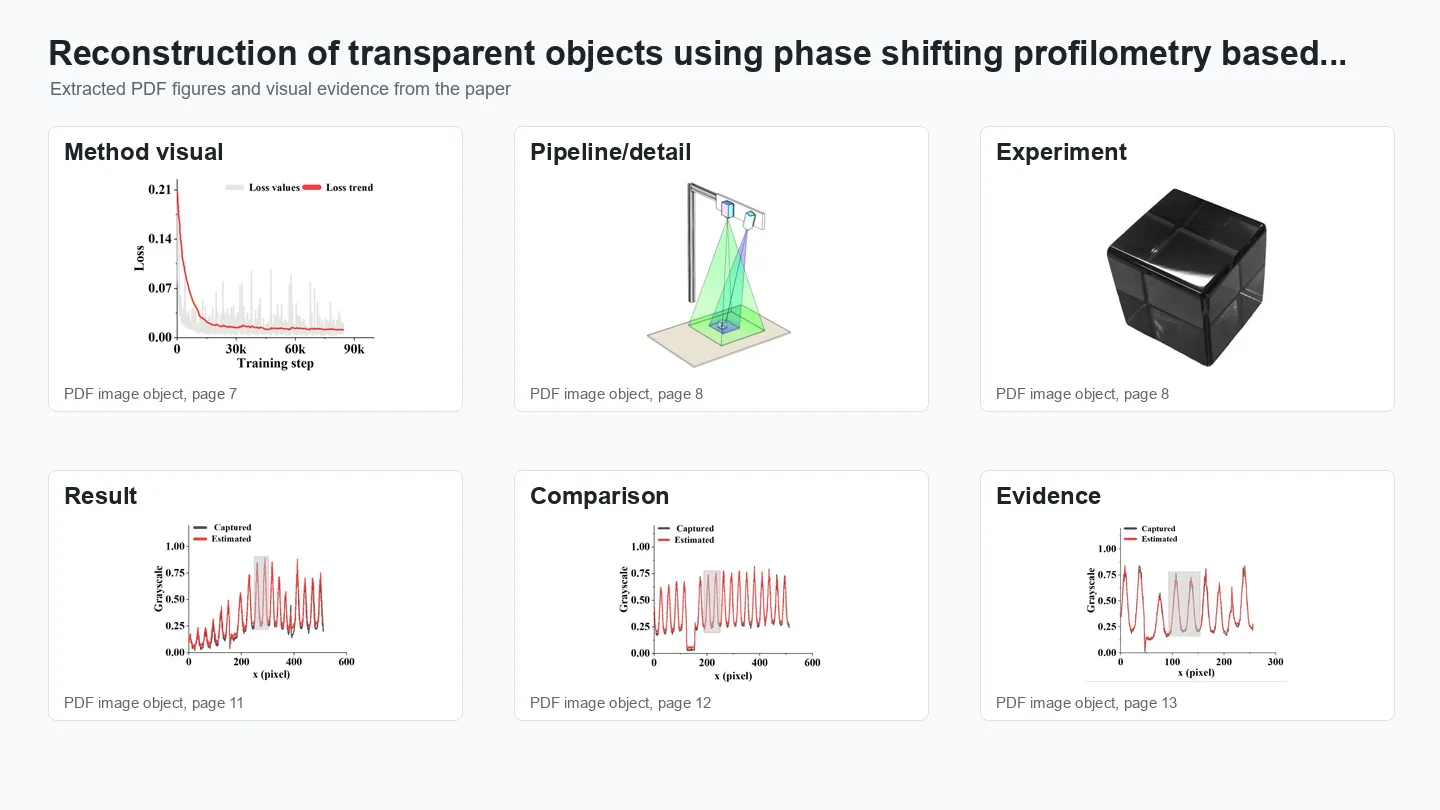 结构光与三维成像Reconstruction of transparent objects using phase shifting profilometry based on diffusion models.Optics Express, 32(8):13342–13356.
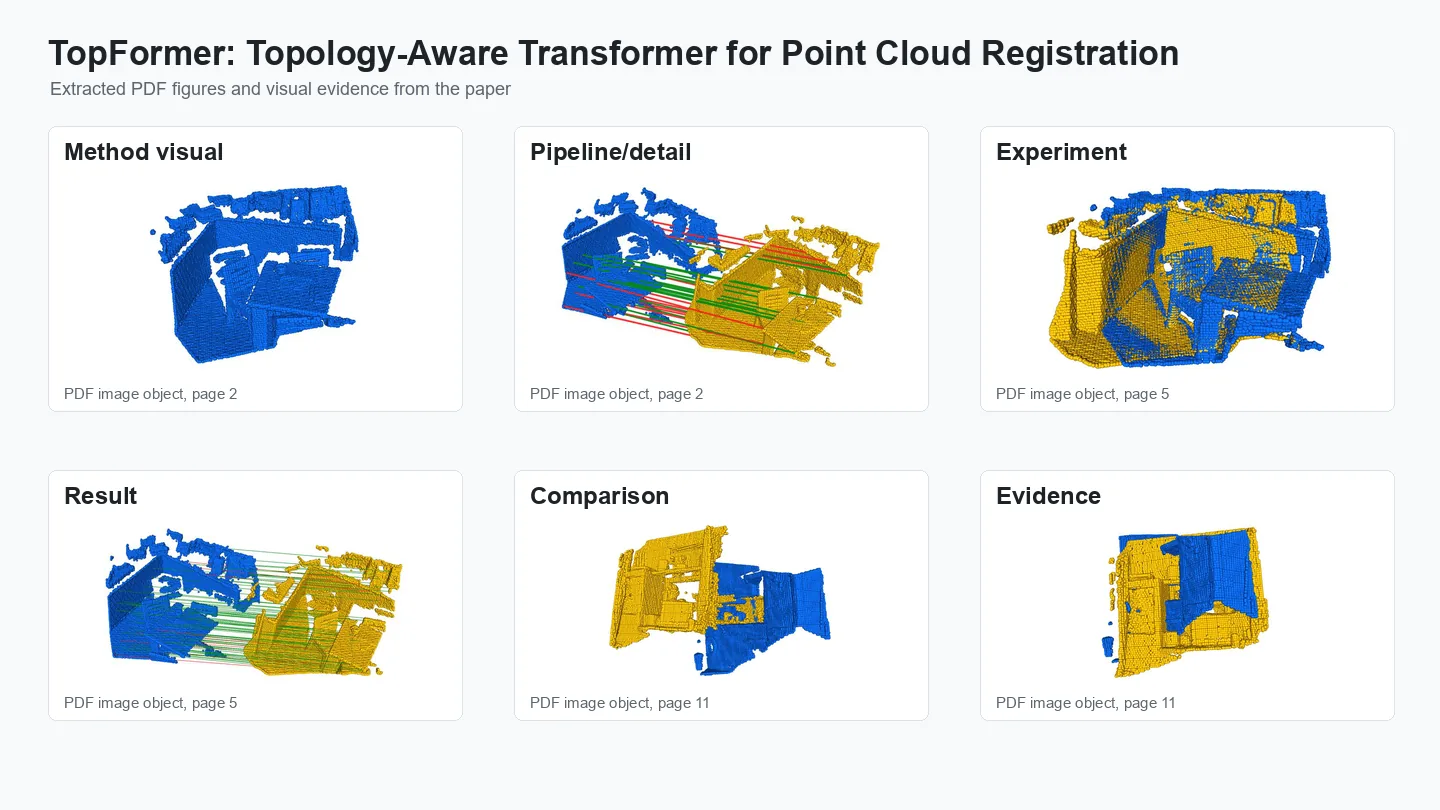 点云配准 CVM 2024TopFormer: Topology-Aware Transformer for Point Cloud Registration.International Conference on Computational Visual Media (CVM) 2024, 112–128.
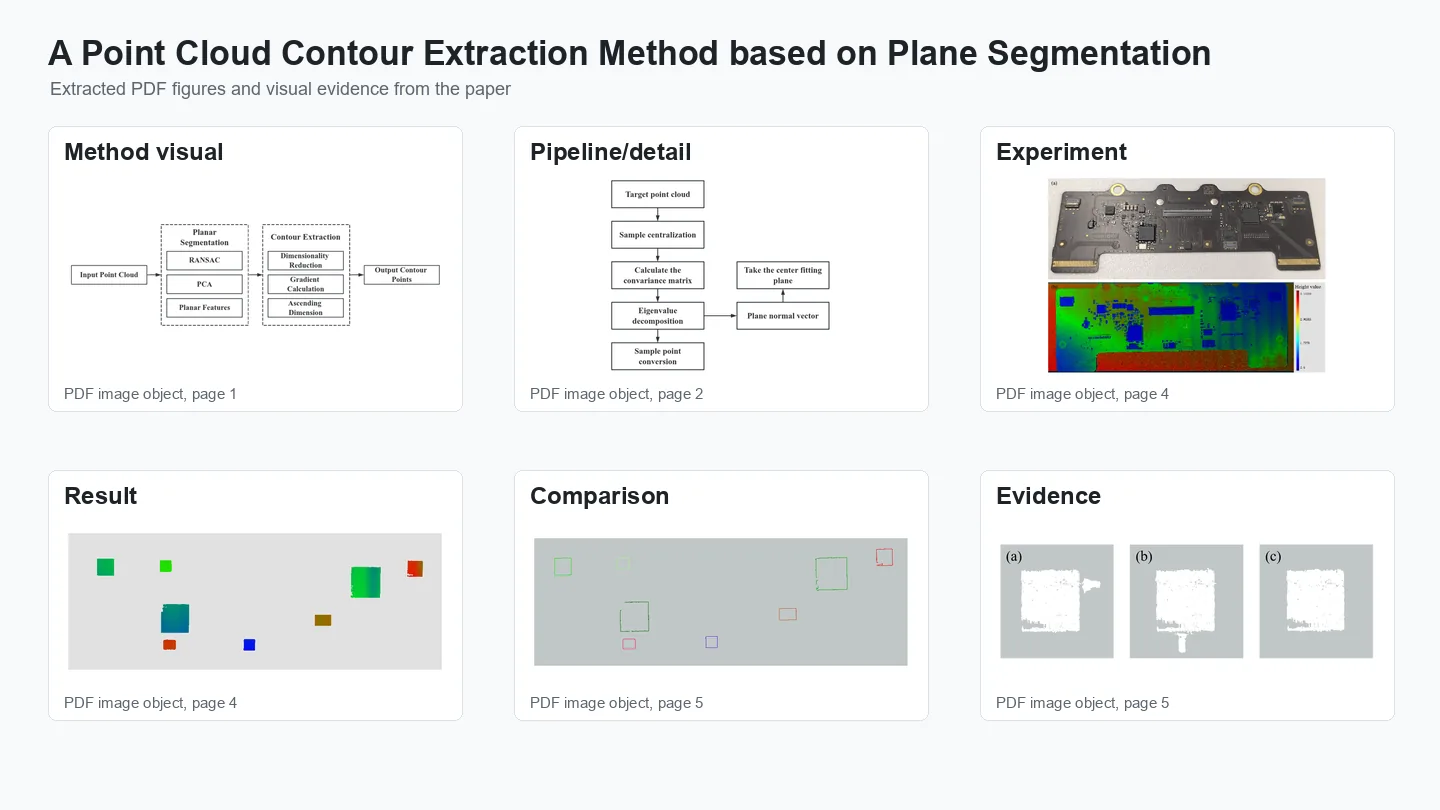 几何处理A Point Cloud Contour Extraction Method based on Plane Segmentation.Frontiers in Computing and Intelligent Systems, 7(2):21-25.
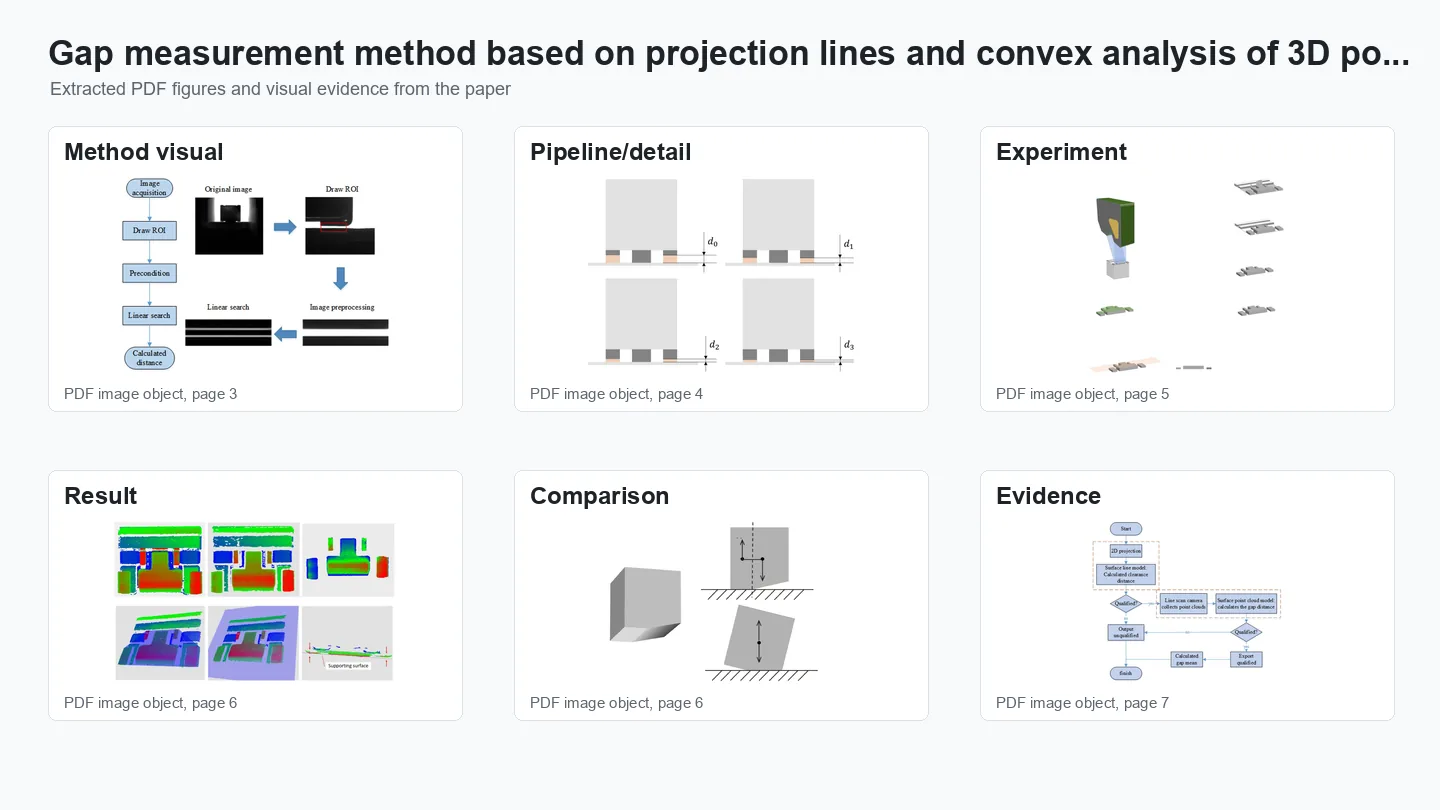 工业检测Gap measurement method based on projection lines and convex analysis of 3D point clouds.Measurement Science and Technology, 35(10):105024.
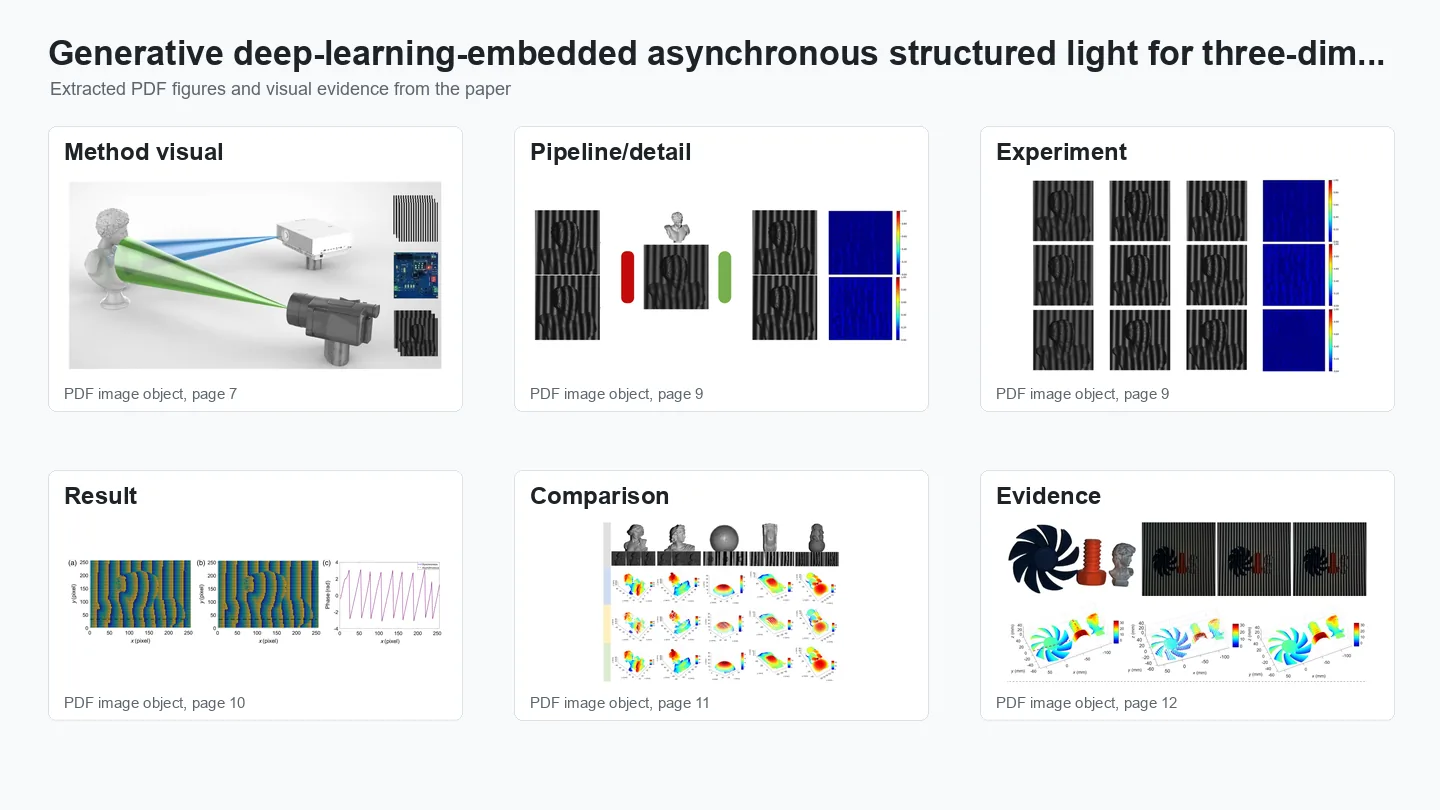 结构光与三维成像Generative deep-learning-embedded asynchronous structured light for three-dimensional imaging.Advanced Photonics, 6(4):046004.
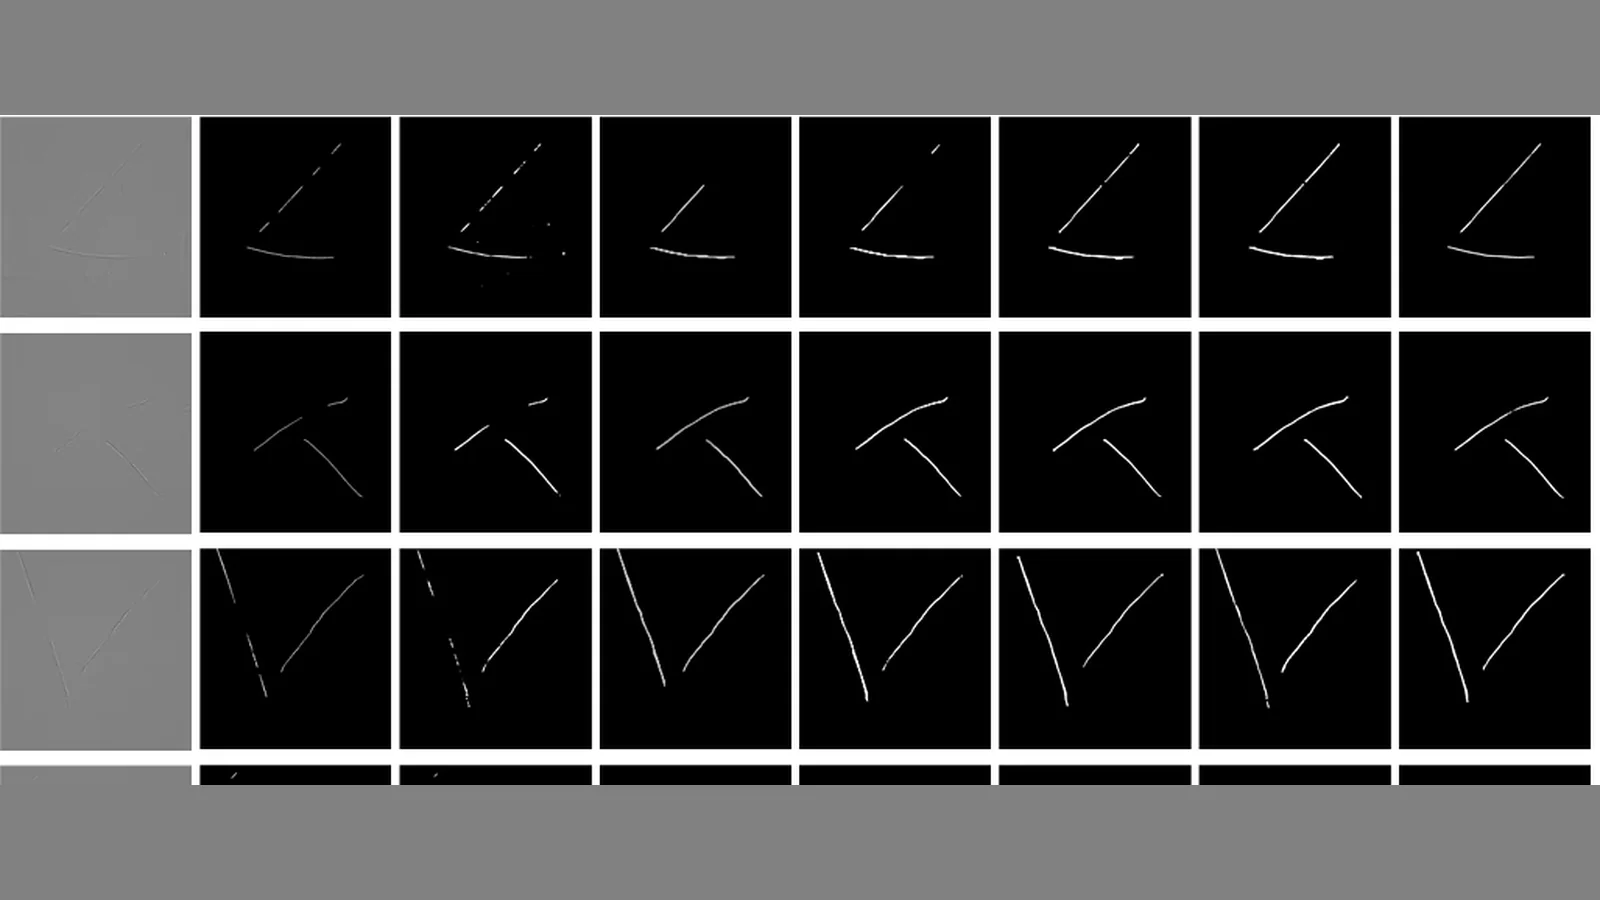 工业检测WTAYOLO: A Detection Model for Weak Scratches on Metal Surfaces.Proceedings of the 2024 7th International Conference on Sensors, Signal and Image Processing, 22-28.
2023
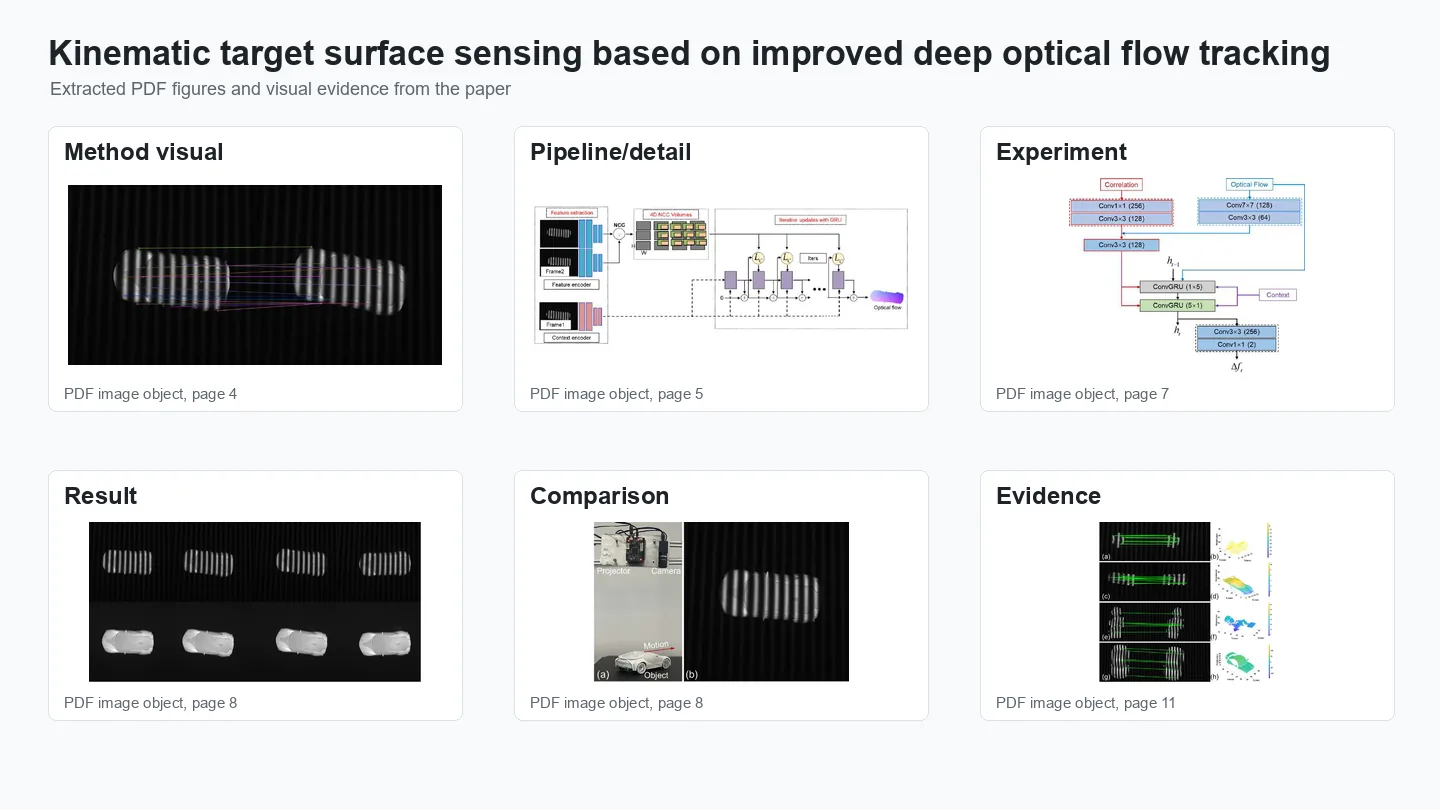 结构光与三维成像Kinematic target surface sensing based on improved deep optical flow tracking.Optics Express, 31(23):39007–39019.
 生物医学与生物识别Deep learning-enabled 3D multimodal fusion of cone-beam CT and intraoral mesh scans for clinically applicable tooth-bone reconstruction.Patterns (Cell Press), 4(9).
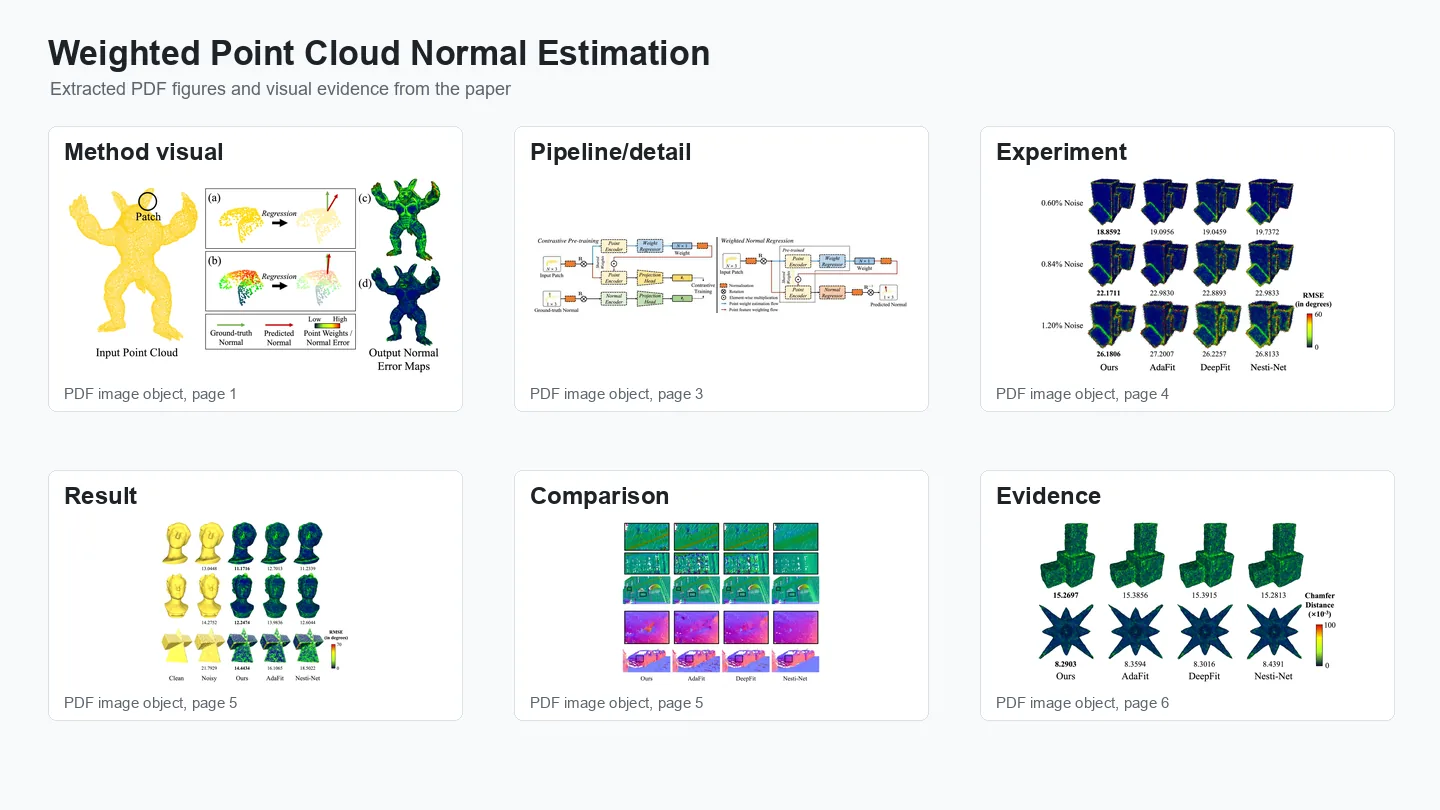 几何处理 ICME 2023Weighted Point Cloud Normal Estimation.IEEE International Conference on Multimedia and Expo (ICME) 2023.
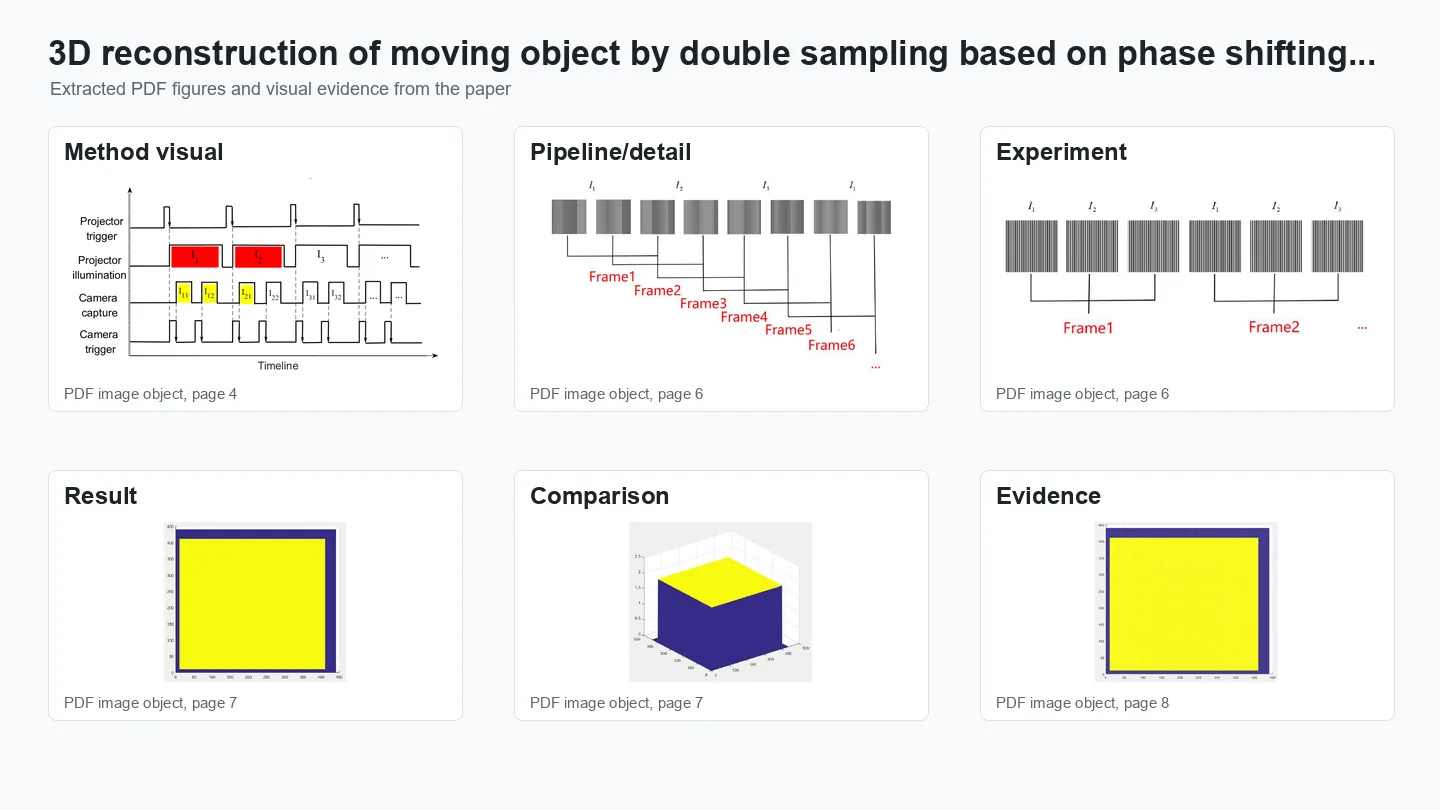 结构光与三维成像 SPIE 20233D reconstruction of moving object by double sampling based on phase shifting profilometry.Ninth Symposium on Novel Photoelectronic Detection Technology and Applications, vol. 12617 (SPIE), 1950–1958.
 结构光与三维成像3D reconstruction of the moving object with double-shooting based on phase shifting profilometry.Infrared and Laser Engineering, 52(12):20220891-1.
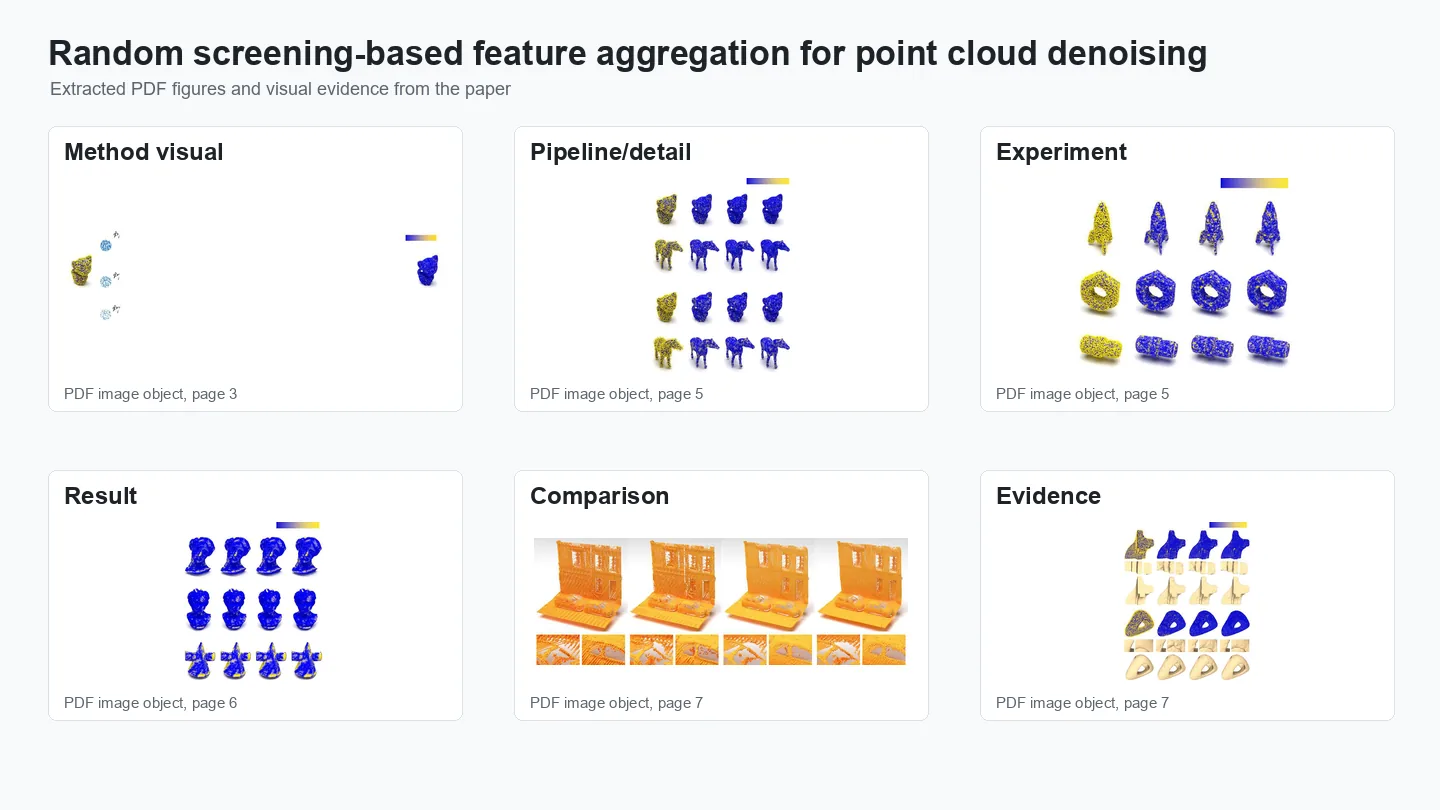 几何处理Random screening-based feature aggregation for point cloud denoising.Computers & Graphics, 116:64–72.
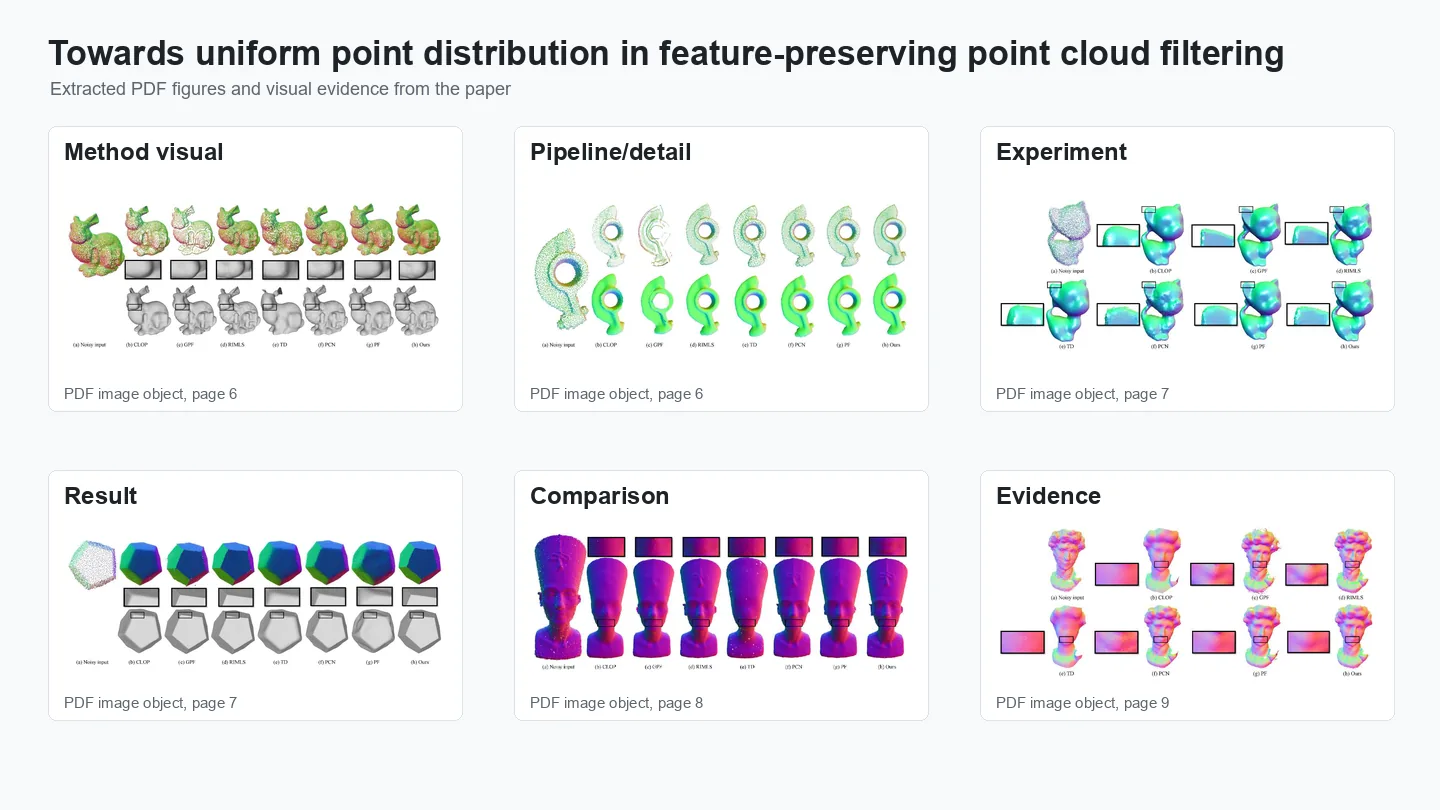 几何处理Towards uniform point distribution in feature-preserving point cloud filtering.Computational Visual Media, 9(2):249–263.
2022
- HPTDD专利与系统High-precision three-dimensional data real-time progressive rendering method and system.CN Patent WO2022257594A1(PCT).[Bib]
2020
 光学与图像处理Automated reconstruction of multiple objects with individual movement based on PSP.Optics Express, 28(19):28600–28611.
- IWPCA几何处理Iteratively weighted principal component analysis and orientation consistency for normal estimation in point cloud.International Journal of Wireless and Mobile Computing, 19(3):267–275.
2019
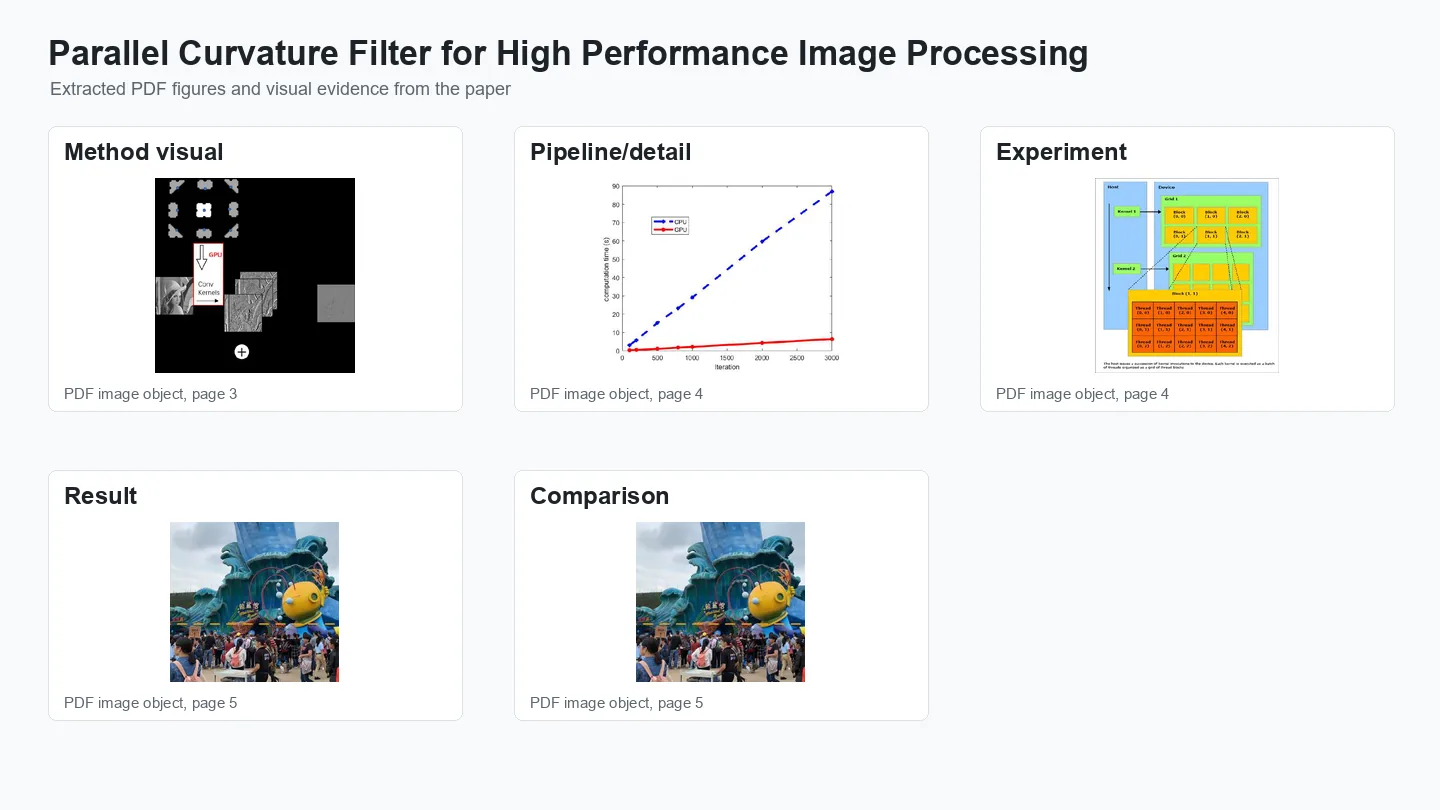 几何处理Parallel Curvature Filter for High Performance Image Processing.IWAIT 2019, vol. 11049 (SPIE), 282–287.
2018
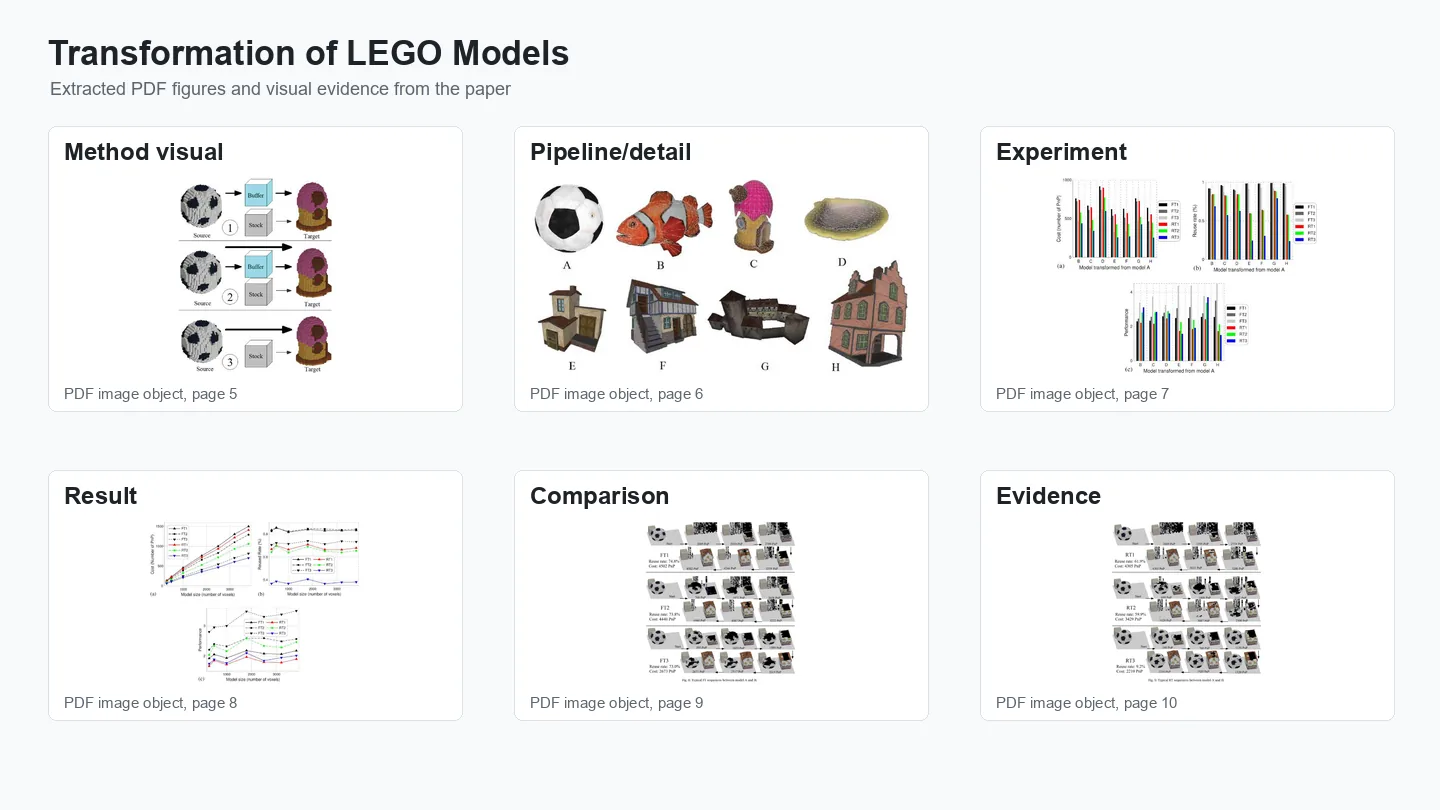
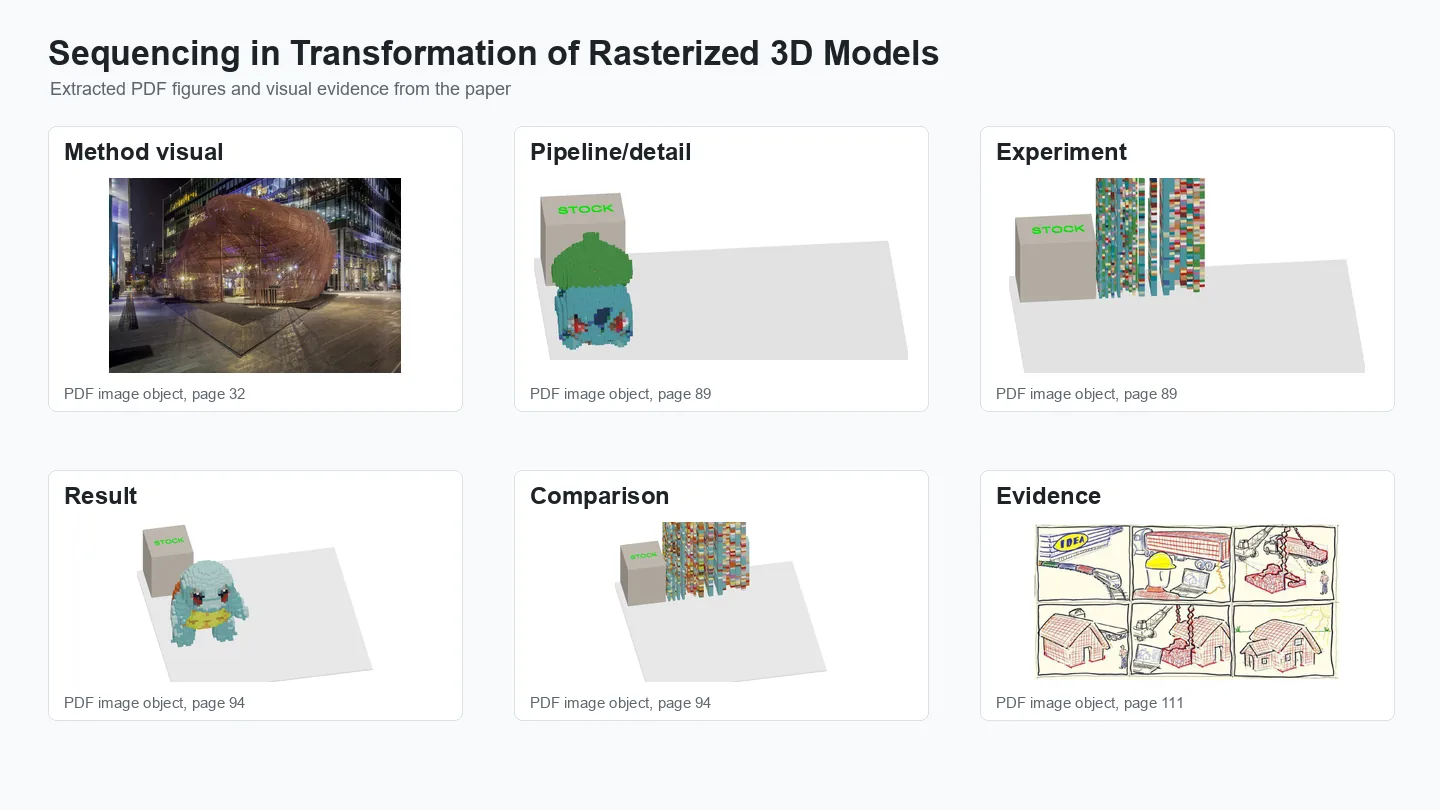 计算设计Sequencing in Transformation of Rasterized 3D Models.Singapore University of Technology and Design.
2017
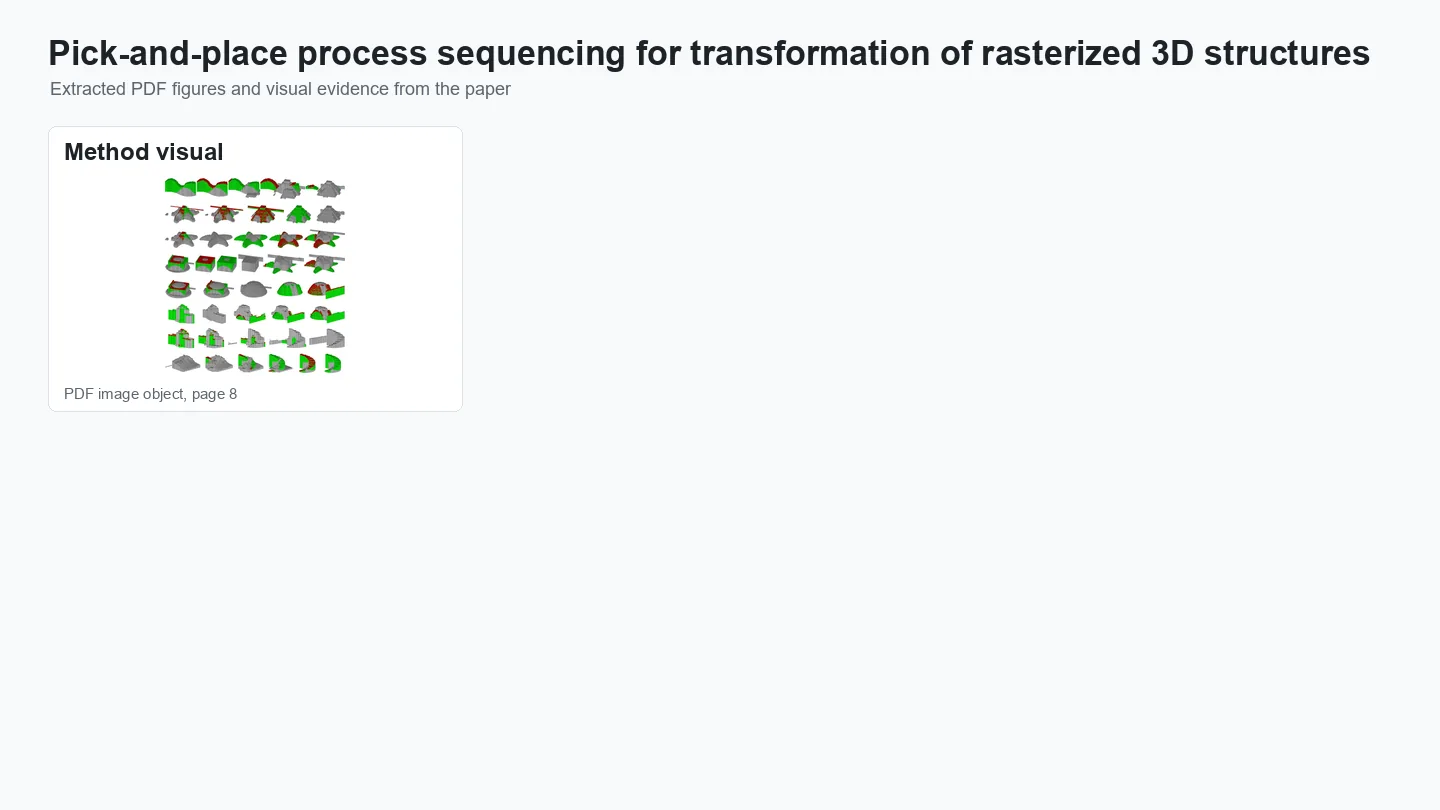 计算设计Pick-and-place process sequencing for transformation of rasterized 3D structures.Automation in Construction, 75:56–64.
2014